


- Photos


Neu
Automatisiert
Flexibel
Metrohub 09TR: Robotic Optical Tracking 3D Scanning System for Automated Scanning & Inspection
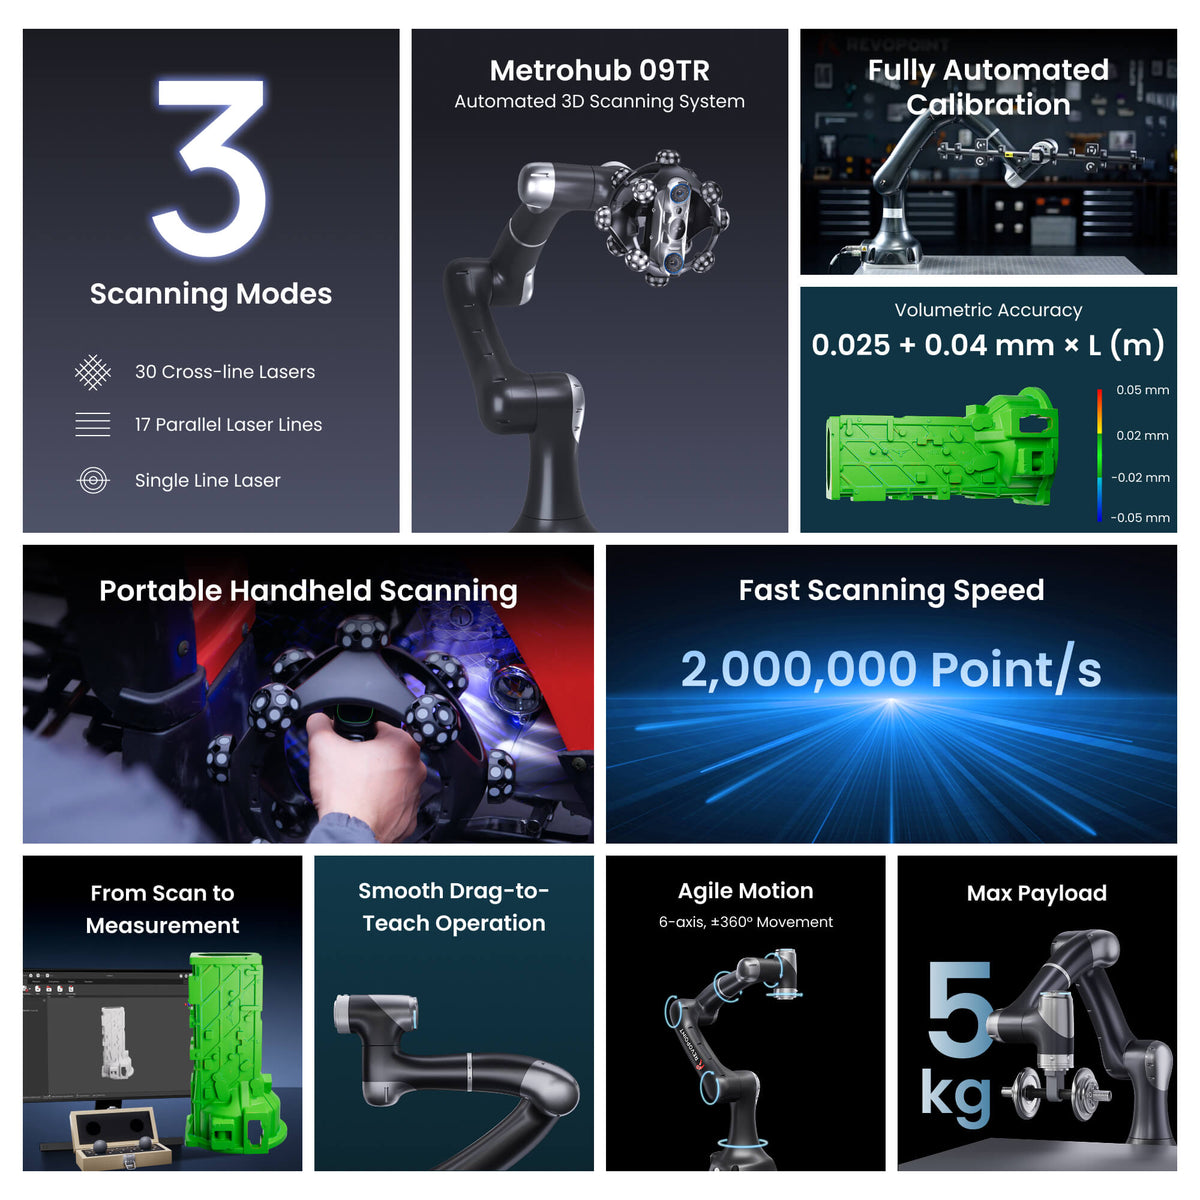
· Volumetrische Genauigkeit: 0,025 mm + 0,04 mm × L (m)
· Dreifacher Blaulaser-Capture
· Schnelle Scangeschwindigkeit 2.000.000 Punkte/s
· Zertifizierte 3D-Messung & Inspektion
· Agile Bewegung 6-Achsen, ±360° Bewegung
· Plug-and-Play-3D-Automatisierung


Vorbestellte Geräte werden ab dem 22. Juni versandt. Software ist vom Umtausch ausgeschlossen, schnelle digitale Lieferung per E-Mail.


Features
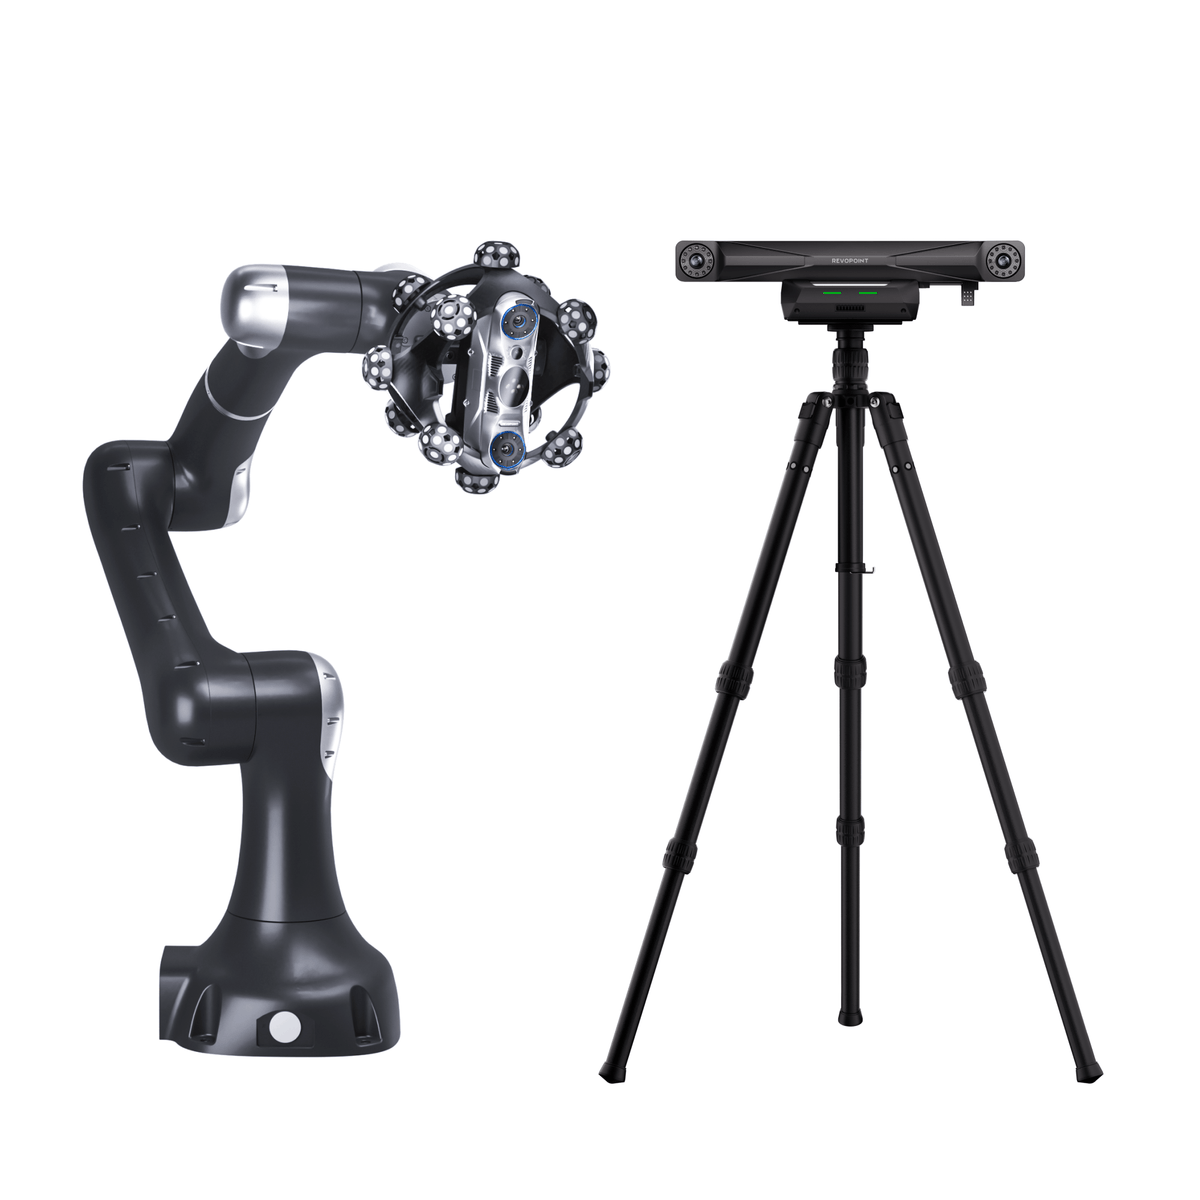
Der Metrohub 09TR vereint einen hochpräzisen *Trackit SR optischen Tracking-3D-Scanner und den 6-Achsen-Cobot Vbot 9, einen CNC-Drehtisch und die TrackBot-Software für automatisiertes Multi-Winkel-Scannen, Messanalysen und Prüfberichte – mit Drag-to-Teach-Pfadplanung, Kraftsensorik und kollaborativem Sicherheitsdesign.


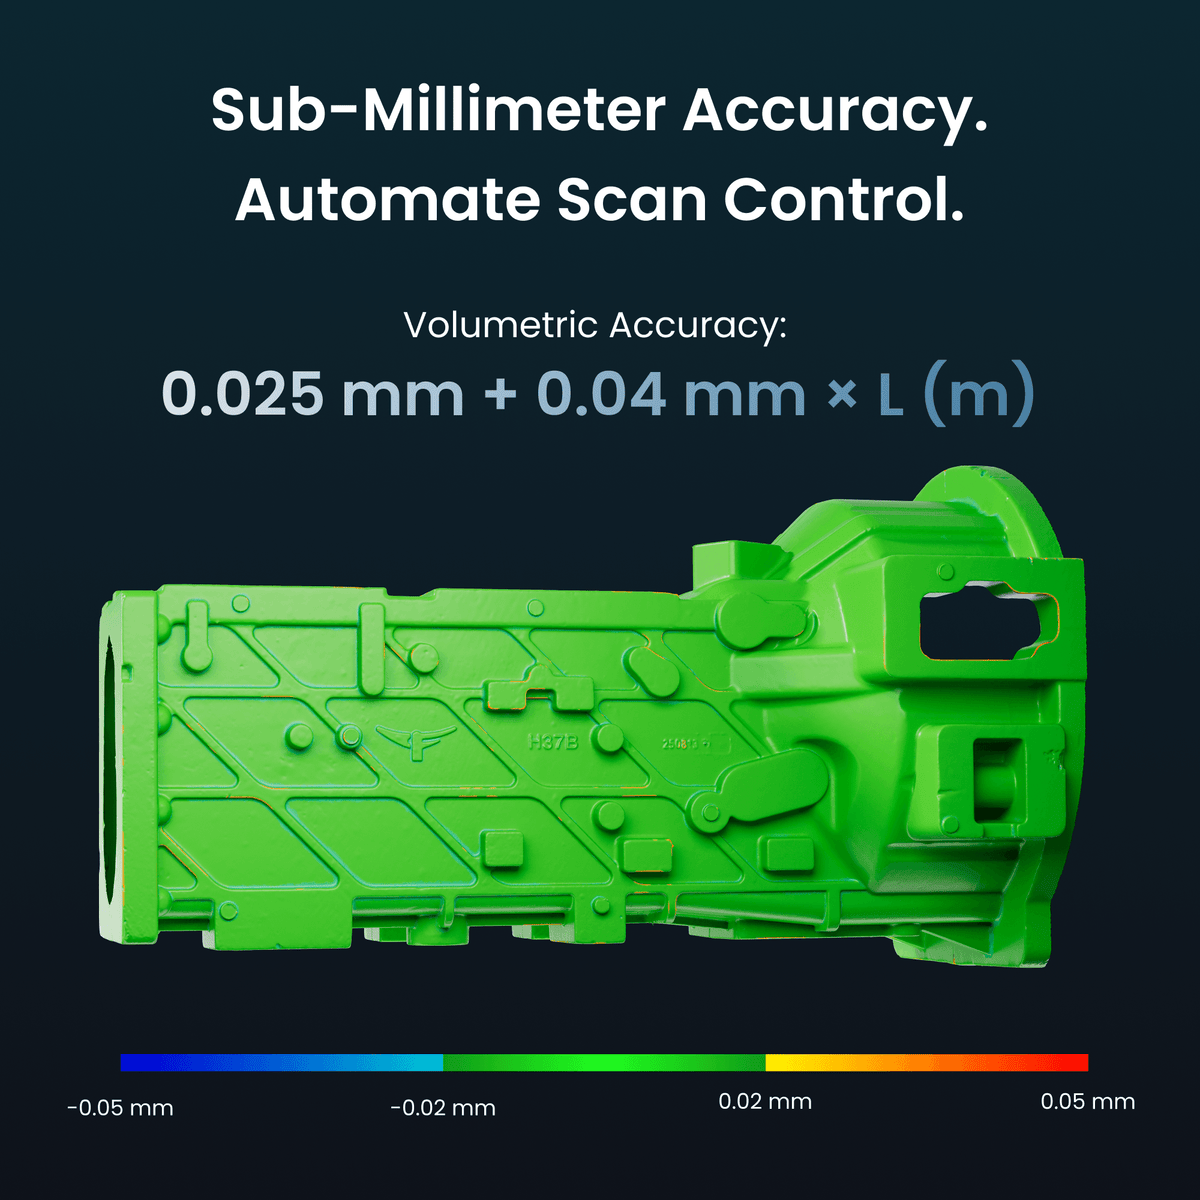
Sub-Millimeter-Genauigkeit. Automatisierte Scansteuerung.
Angetrieben vom 6-Achsen-Vbot 9 deckt das automatisierte Multi-Winkel-Scannen gekrümmte, freiformige und tiefe Hohlraumbauteile ab.
Volumetrische Genauigkeit:
0,025 mm + 0,04 mm × L (m)
Fusionierter Punktabstand
Bis zu 0,05 mm


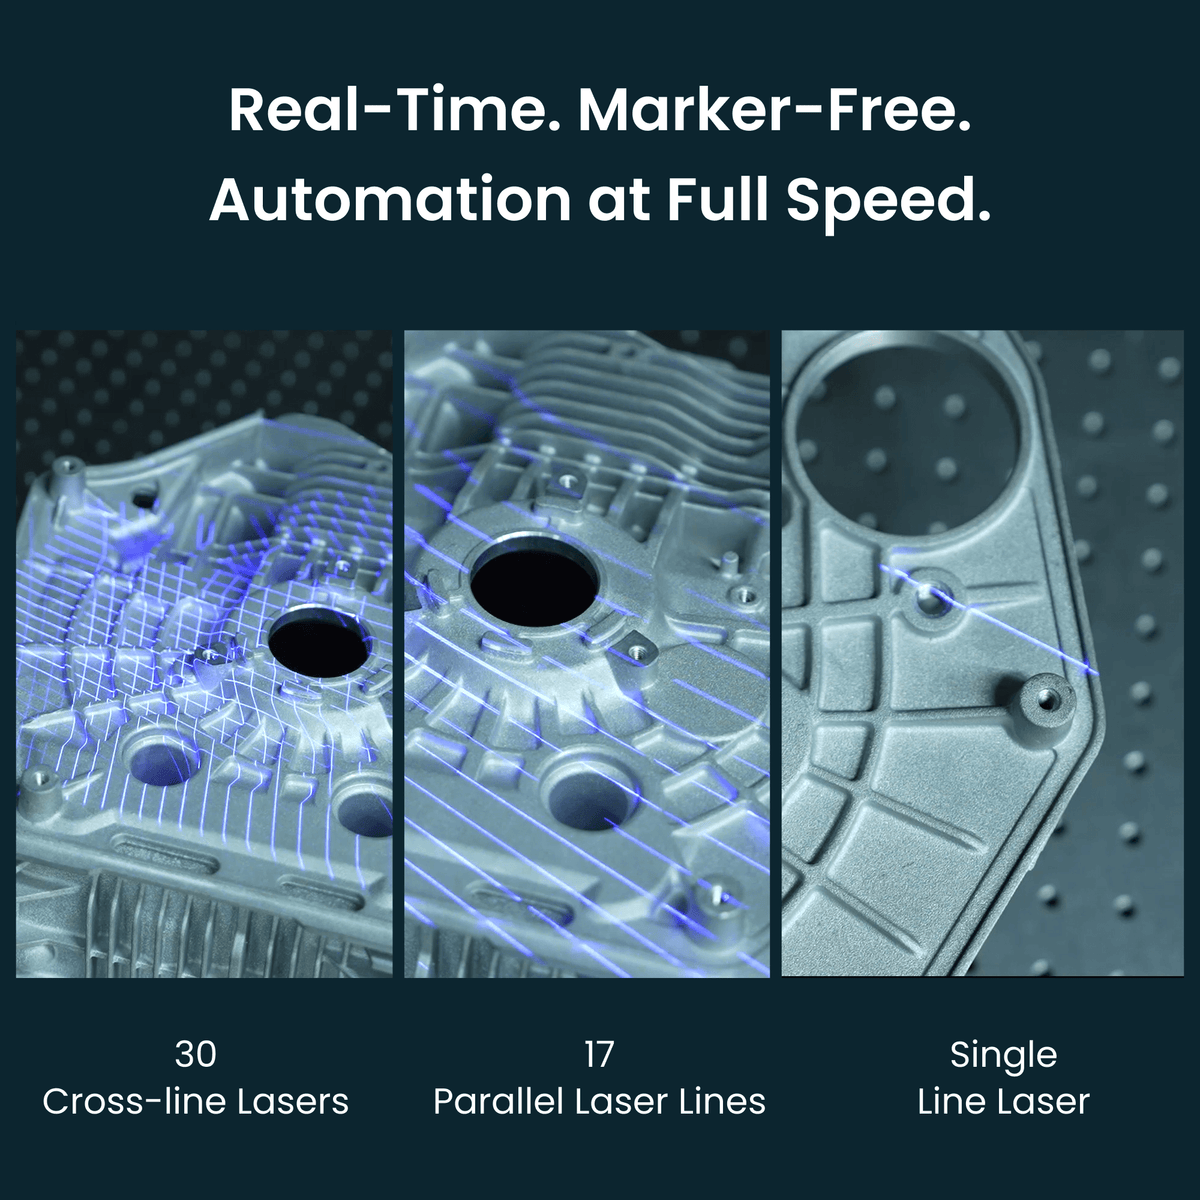
Echtzeit. Markerfrei. Automatisierung mit voller Geschwindigkeit.
Die 30 Kreuzlinien-, 17 Parallellinien- und Einzellinien-Laser des Trackit SR ermöglichen markerfreies Scannen von schwarzen, reflektierenden und metallischen Oberflächen mit bis zu 2.000.000 Punkten/s.


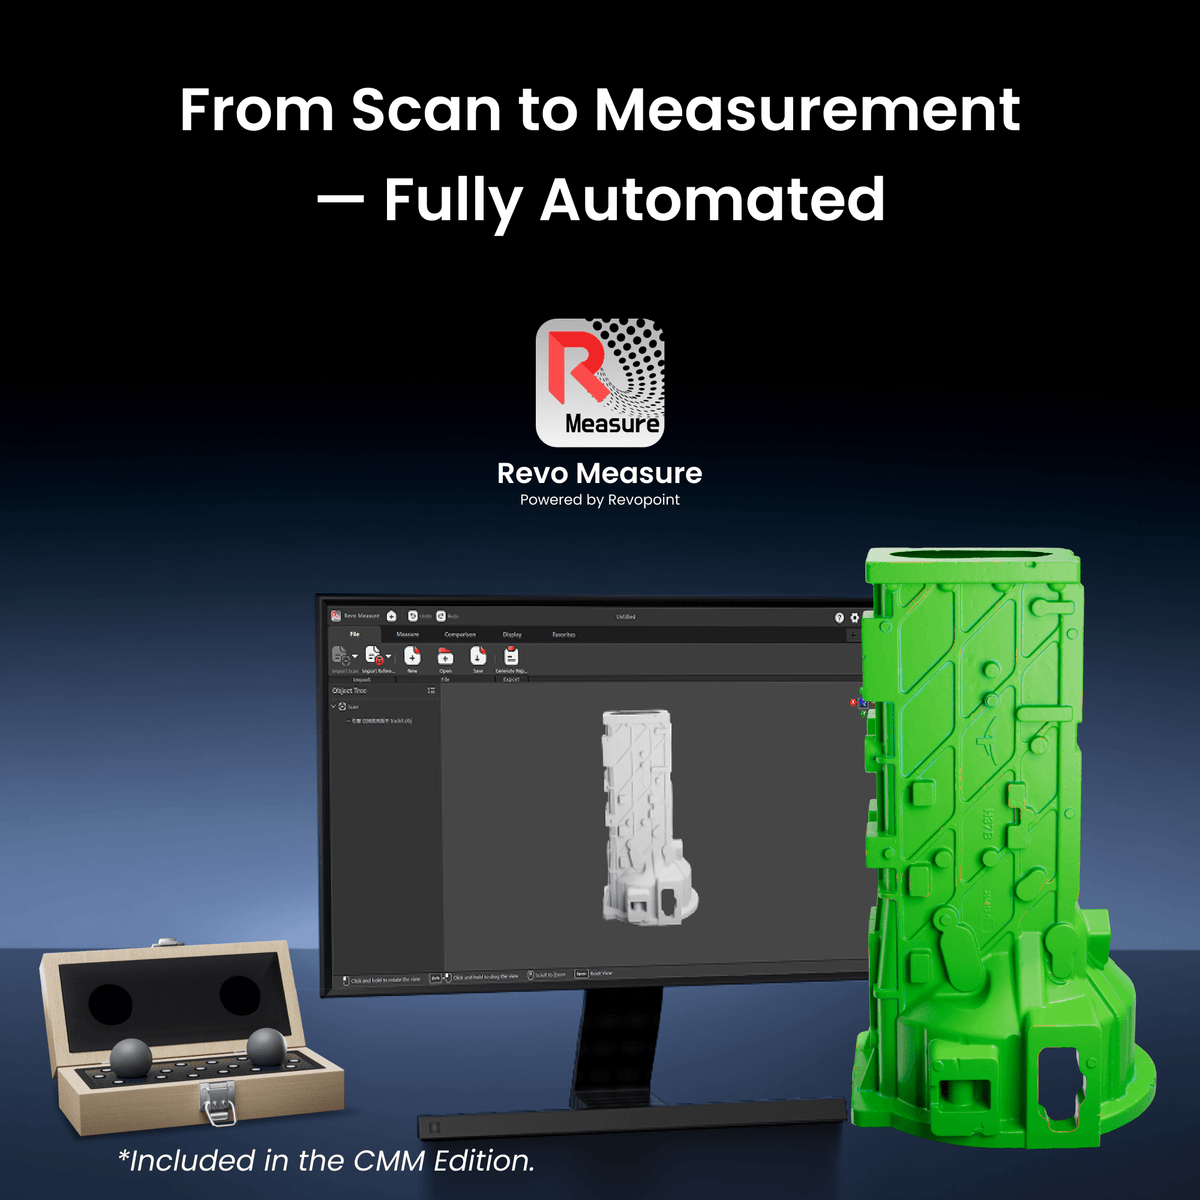
Vom Scan zur Messung — vollständig automatisiert
Der Metrohub 09TR unterstützt vordefinierte Vorlagen für Batch-Prüfabläufe — löst automatisch *Revo Measure für Maßprüfung, GD&T-Analyse und Ergebnisausgabe aus.
*In der CMM Edition enthalten.


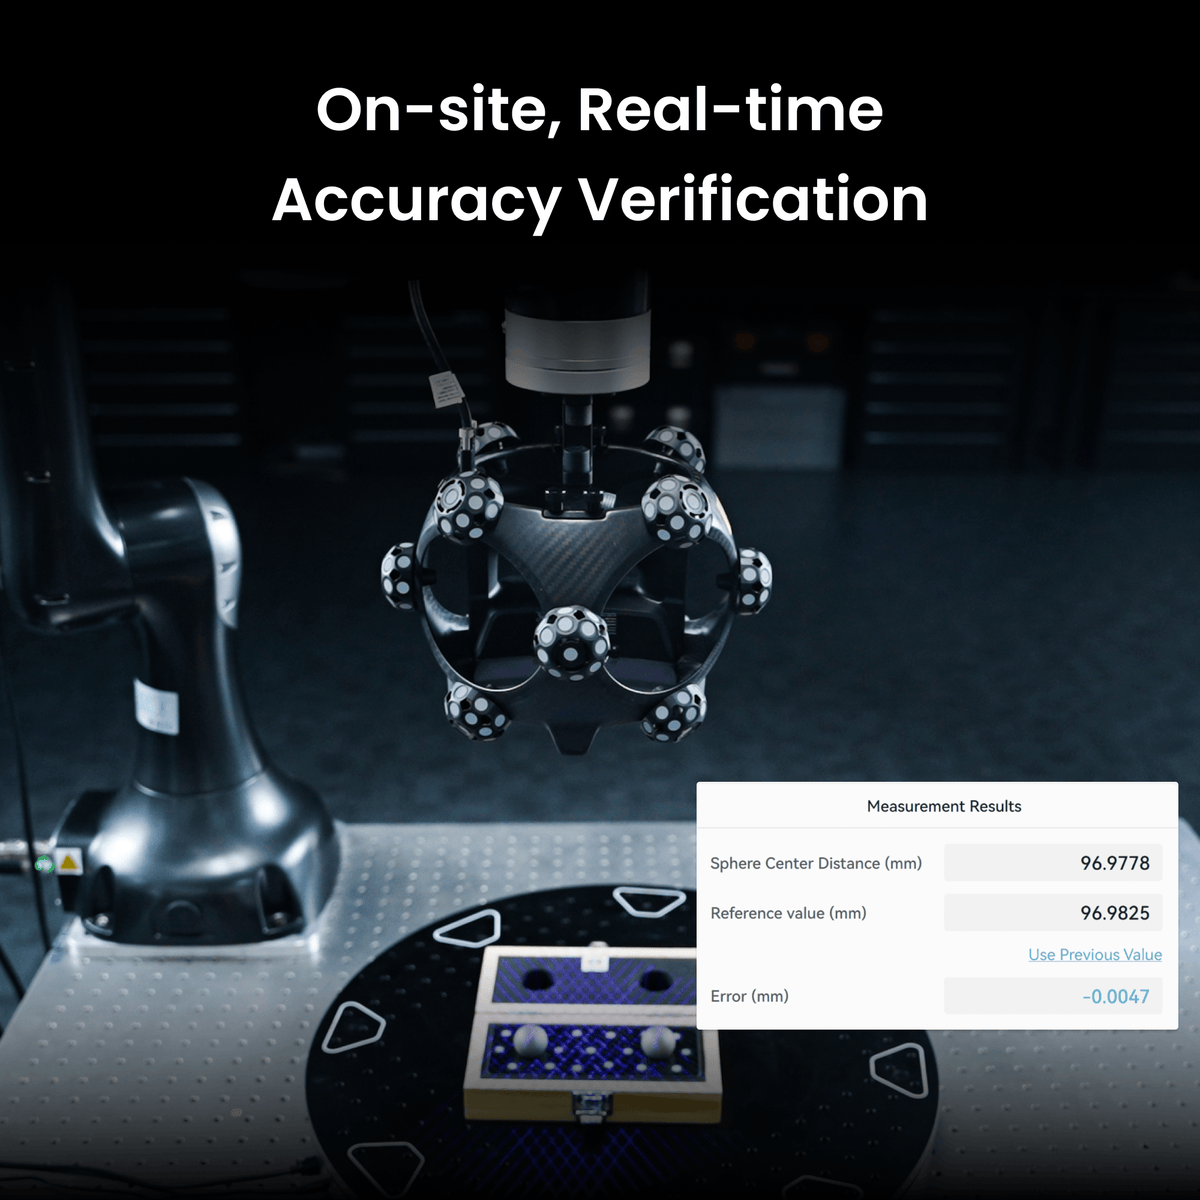
On-site, Real-time
Accuracy Verification
Metrohub 09TR's metrology-grade *Ball Plate and automated verification workflow deliver instant on-site accuracy confirmation in TrackBot.
*Included in the CMM Edition.

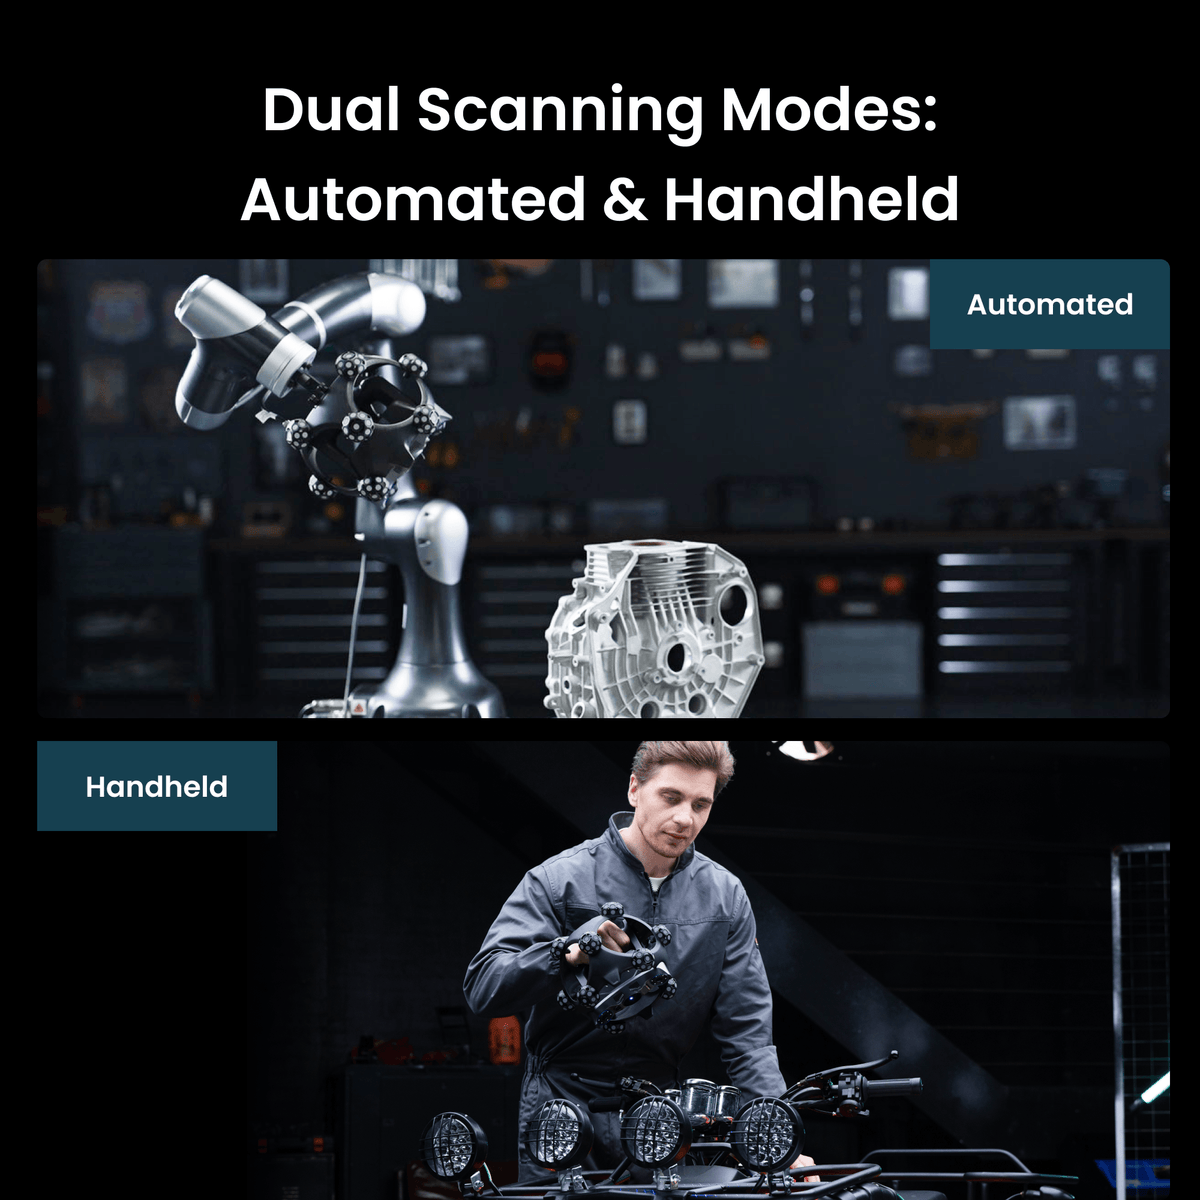
Dual Scanning Modes: Automated & Handheld
It also operates wirelessly and independently for standalone marker scanning.


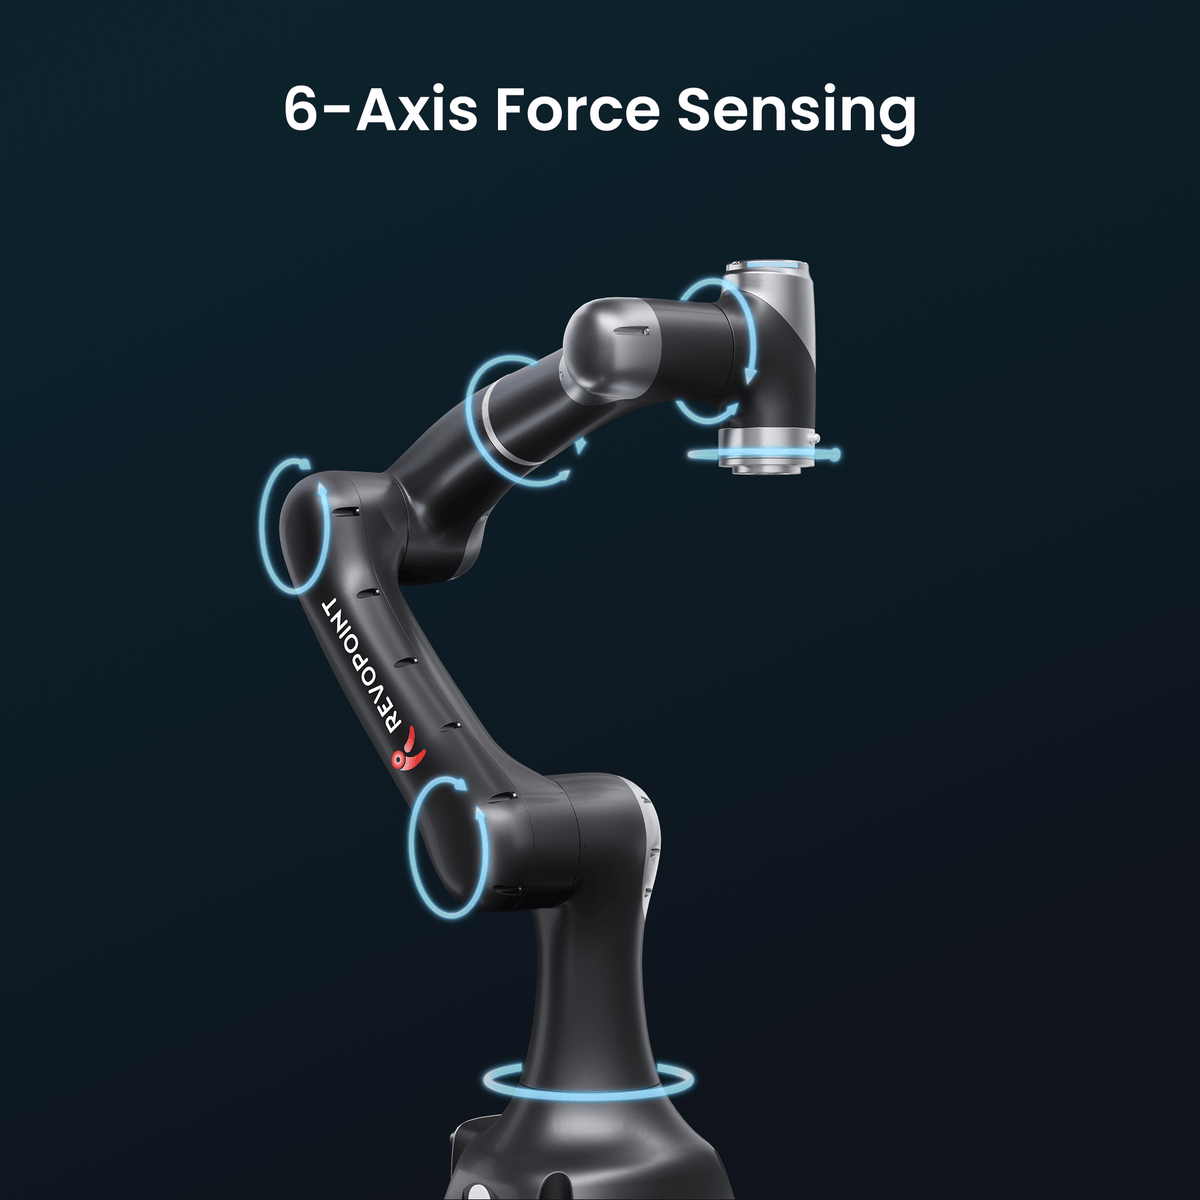
6-Achsen-Kraftsensorik — jede Bewegung spüren
Die integrierten 6-Achsen-Kraftsensoren des Vbot 9 liefern ultrasensibles Kraft-Feedback und Echtzeit-Kraftregelung.


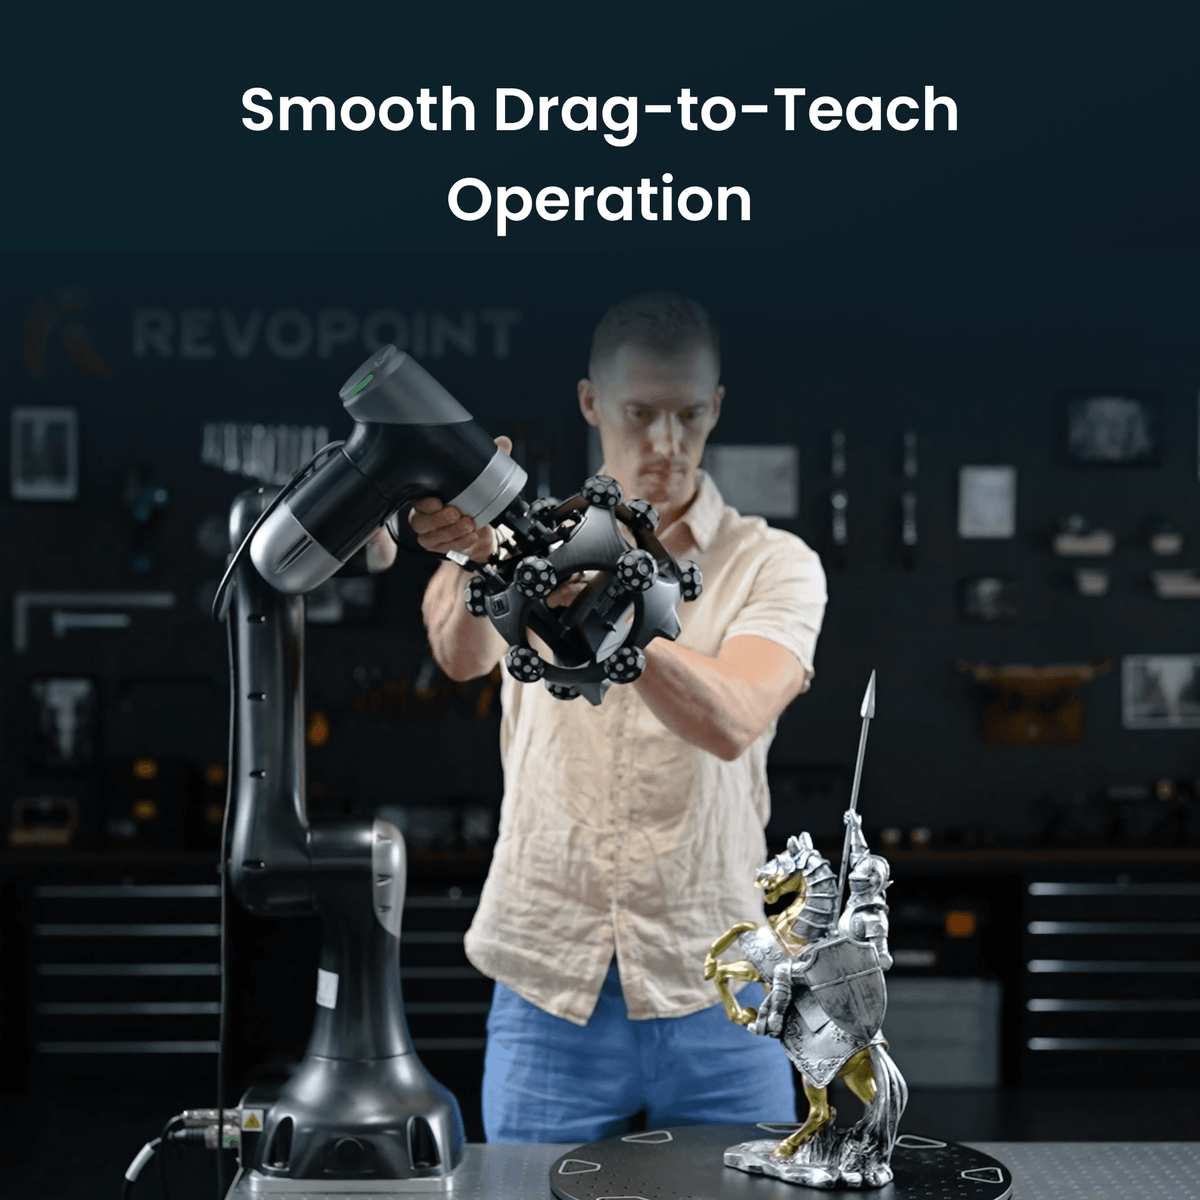
Reibungslose Drag-to-Teach-Bedienung
Vor-Scan zur Überprüfung von Roboterpfaden, Scanabdeckung und Datenqualität — maximiert den Scanerfolg.


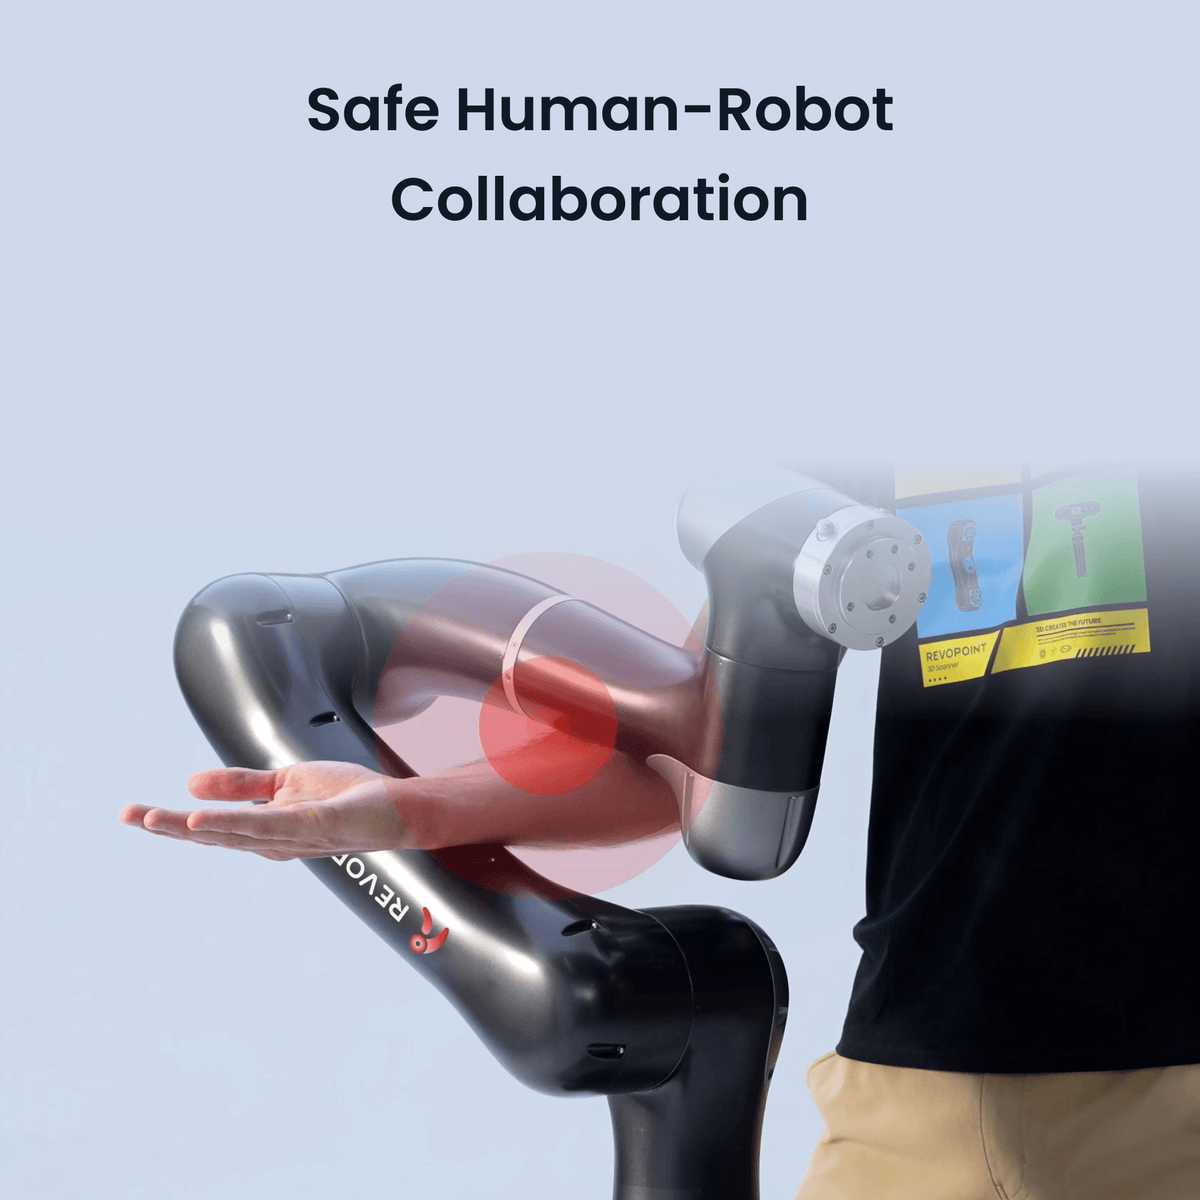
Security Collaboration
Work safely alongside the robot — no safety fences required. 1N force sensitivity ensures complete collision protection.


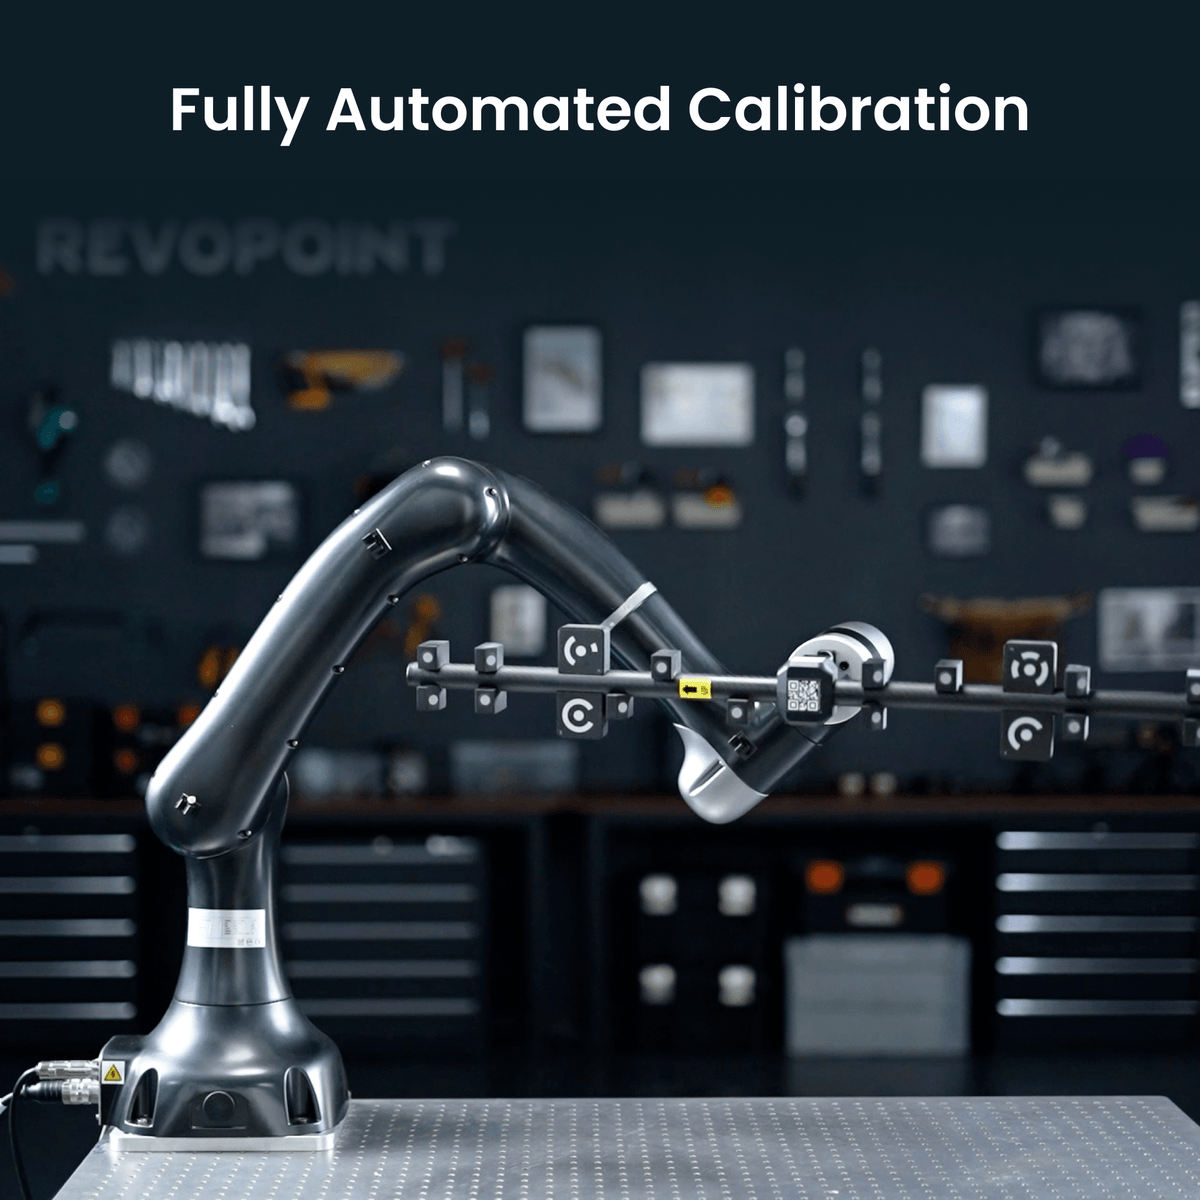
Schnelle automatisierte Kalibrierung
Erreichen Sie mit dem Auto-Kalibrierungssystem von Trackit SR und Vbot 9 eine perfekte Multi-Pose-Kalibrierung frei von menschlichen Fehlern — zuverlässig, präzise und einfach.


Entwicklungskit für Drittanbieter
Ein TCP/IP-Steuerprotokoll verbindet Drittanbieter-Anwendungen mit Revo Track für die Echtzeitsteuerung von Scan und Nachbearbeitung
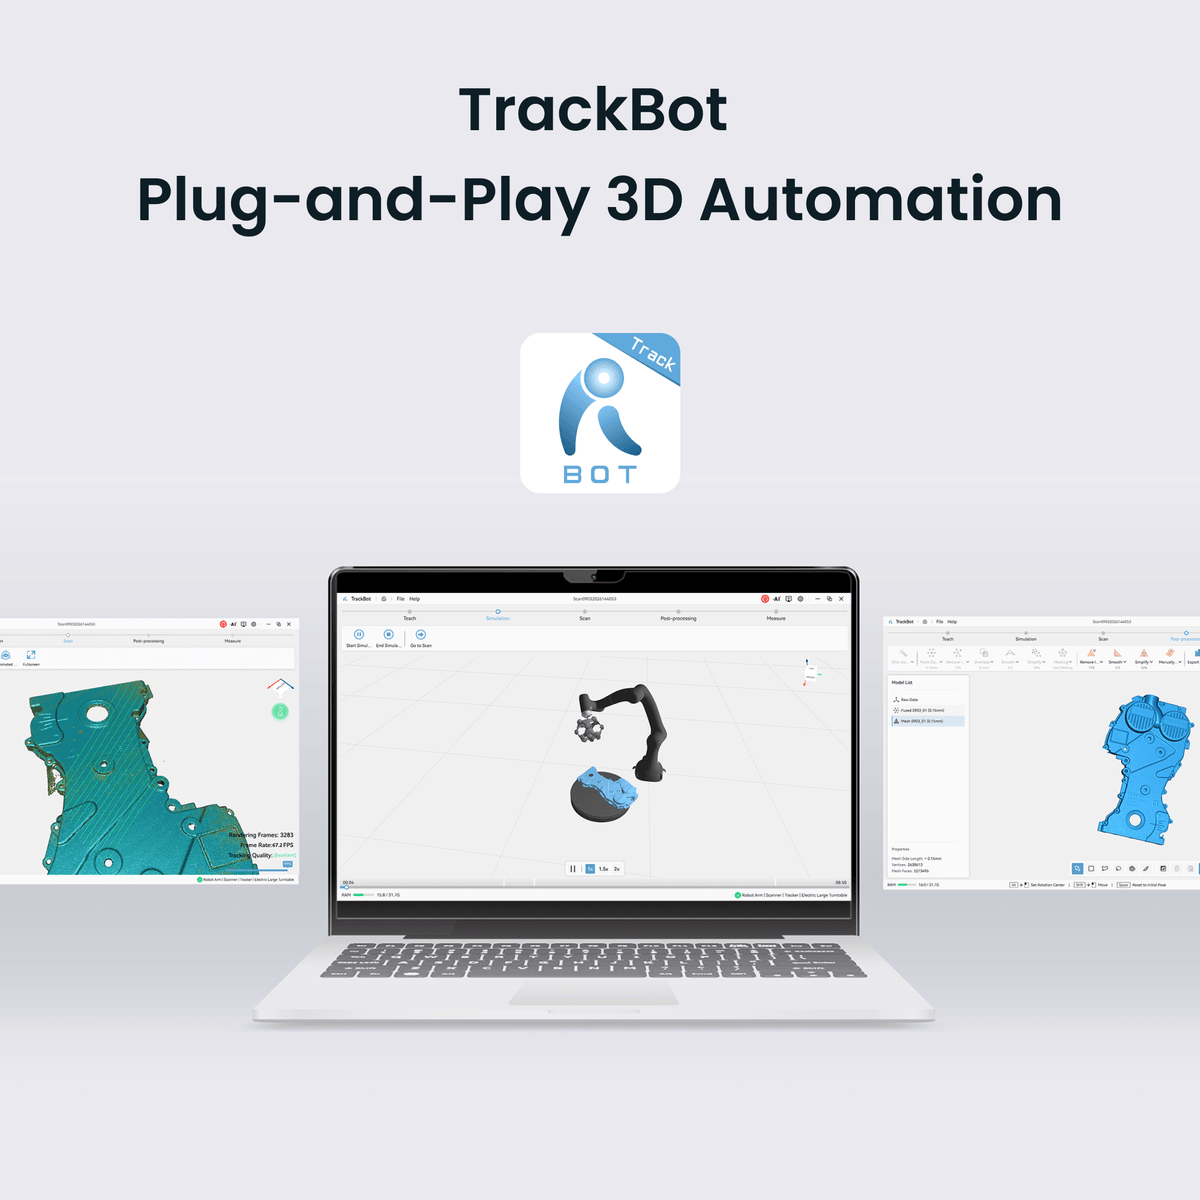
TrackBot — Plug-and-Play 3D Automation
Set up automated scans in minutes — drag-to-teach, CAD-to-path, or vision-to-path. No programming required.


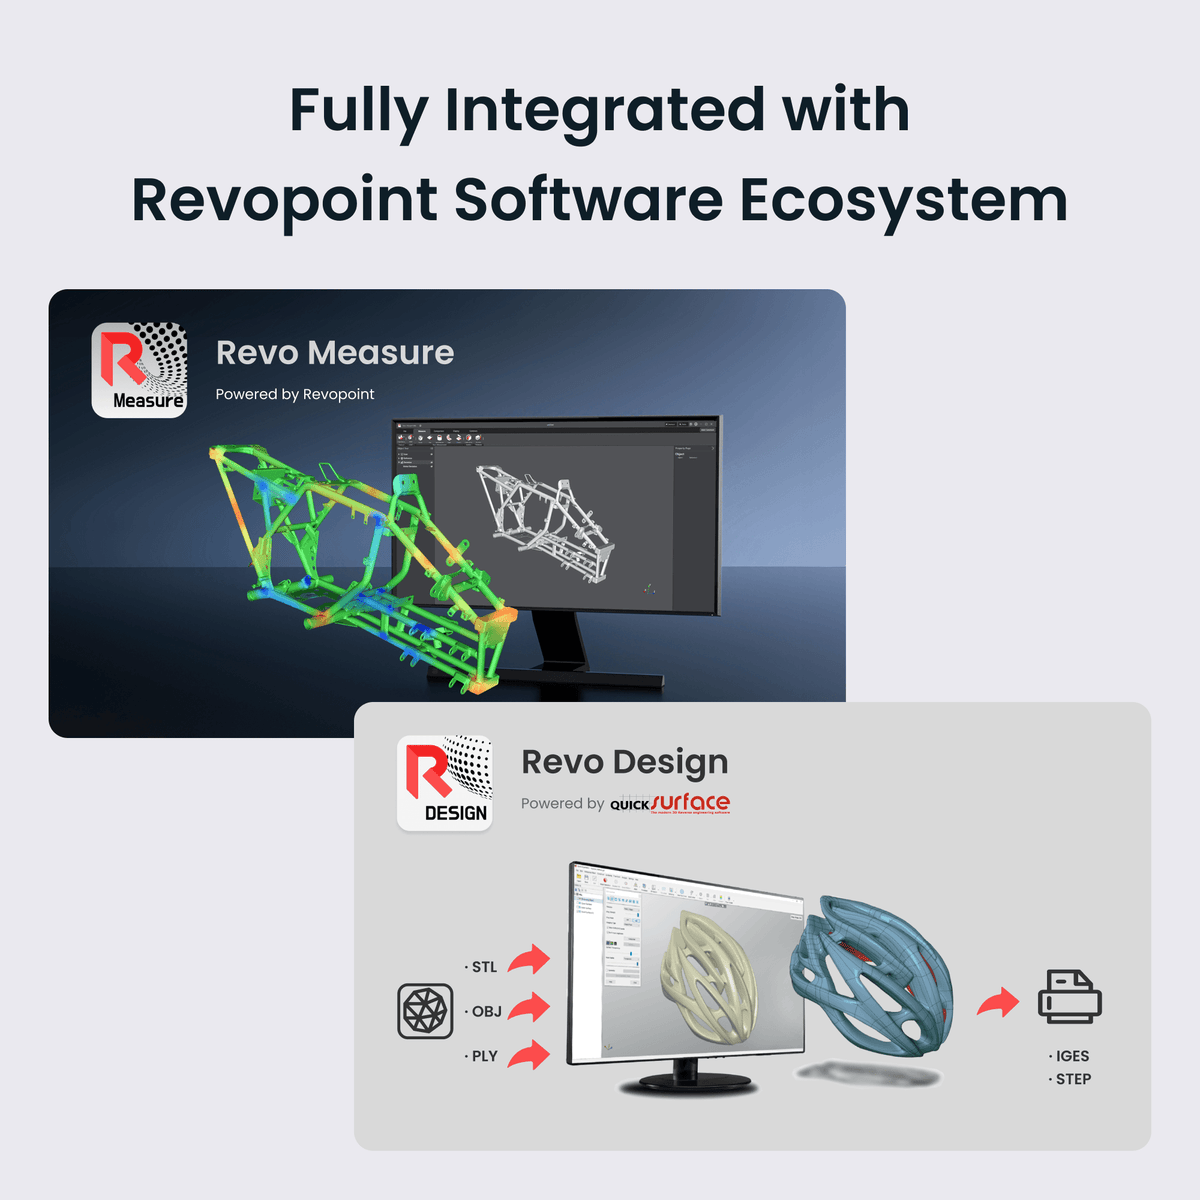
Fully Integrated with
Revopoint Software Ecosystem
Integrate with Revo Measure for one-click measurements,
CAD comparison, and 10+ GD&T functions.


Abnehmbar & Flexibel
Der Trackit SR Scanner lässt sich vom Vbot 9 abnehmen für unabhängigen Handbetrieb – für die Flexibilität, zwischen vollautomatisiertem robotergestütztem Scannen und manuellem Scannen zu wechseln, ohne Ihr Setup zu ändern.

Trackit SR Tracking 3D Scanner
Detach the scanner for wireless, standalone markerless scanning — ideal for complex structures, or any scenario where the robotic arm cannot reach. Maintains high-precision scanning accuracy in both robotic and handheld modes.
Learn More
Robot Vbot 9
Lightweight, 6-axis cobot with a 919 mm working radius and 1N force sensitivity for safe human-robot collaboration. Pairs seamlessly with the Trackit SR for automated multi-pose scanning across complex workpieces.
ExploreProfessional Solutions

Automatisiertes 3D-Scannen
Automatische Planung von Scanpfaden mit mehreren Posen über die Blade-Oberflächen und die Grundmerkmale hinweg mithilfe einer KI-gestützten Kollisionsvermeidung – zur Erfassung einer 360°-Punktwolke in einer einzigen Aufstellung.

Additive Fertigung
Erfassen Sie automatisch Punktwolken von Überhängen, Gitterstrukturen und inneren Hohlräumen – und generieren Sie STL-Daten für Modellreparatur, Prozesskompensation und Nachfertigung.

Gießen und Schmieden
Scannen Sie Gussteile und heiße Werkstücke automatisch mit Echtzeit-Wärmekompensation – zur schnellen Identifizierung von Materialabweichungen, Schrumpfung und Oberflächenfehlern, um die Formkorrektur zu beschleunigen.

Kunststoffe
Automatisierte Inspektion für spritzgegossene, blasgeformte und tiefgezogene Teile – zur Erkennung von Schrumpfung, Verzug, Rückfederung und Konturverformung in der Serienproduktion.

Metallumformung
Automatisches Scannen von Schweißnähten, Bohrungspositionen und Oberflächenprofilen an Karosserieblechen – mit Punktwolkenvergleich gegen CAD über offene TCP/IP-Schnittstellen für die Integration in die Produktionslinie.

Batterieinspektion
Mehr-Posen-Roboterscanning erfasst alle sechs Seiten, Dichtungszonen und Anschlüsse prismatischer Batteriegehäuse – zur Erkennung von Ausbeulungen, Dellen, Dichtungsversatz und Maßabweichungen.
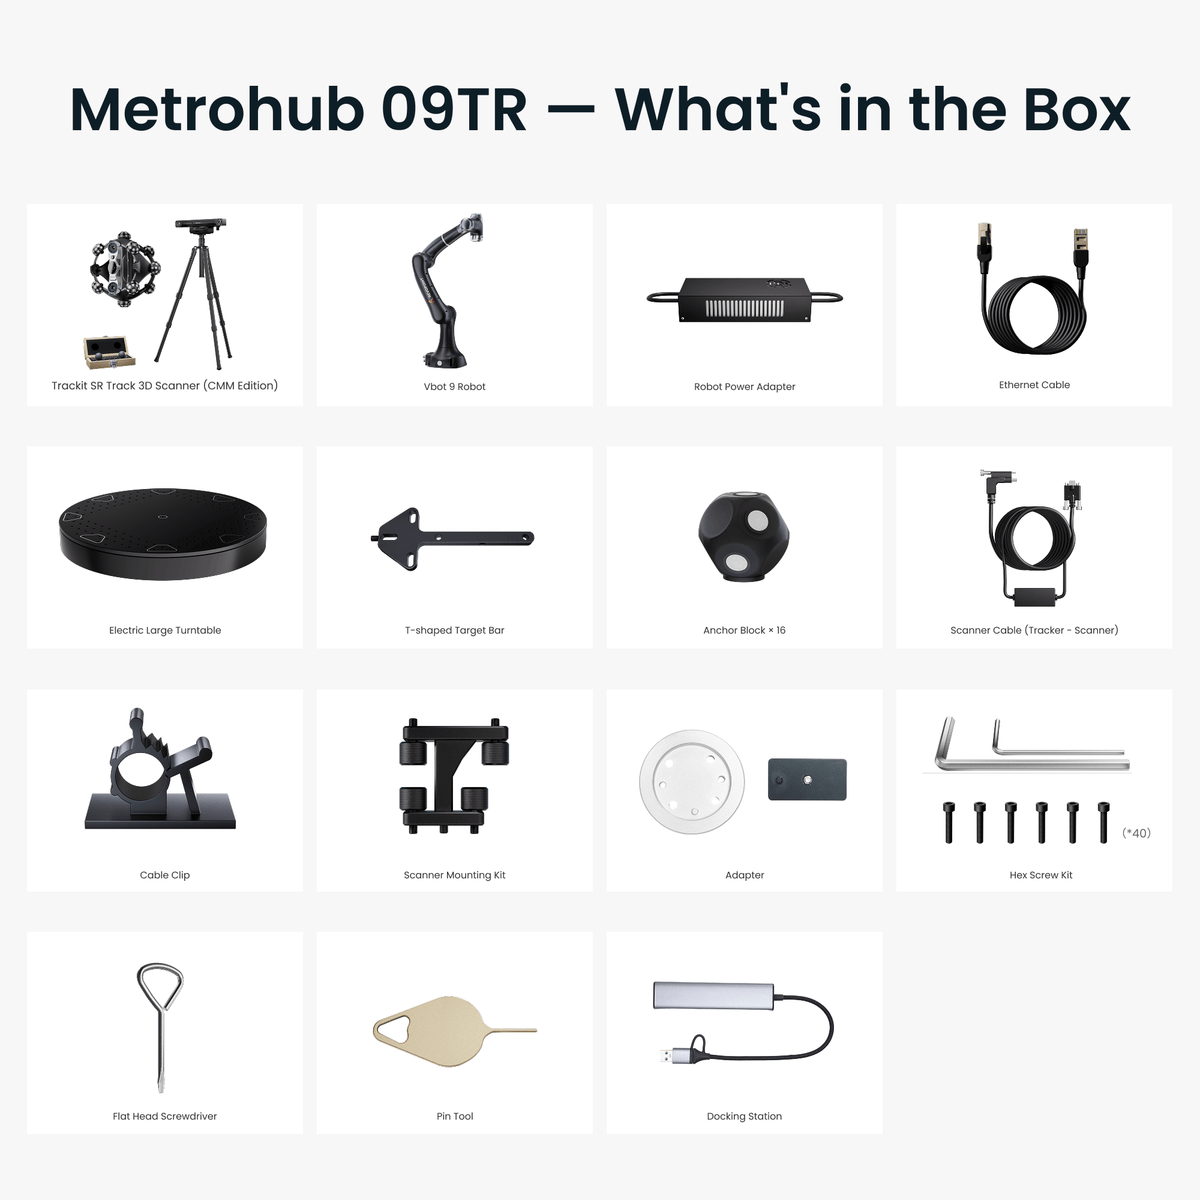
What’s in the Box?
Standard-Edition

Trackit SR Track 3D-Scanner (KMM-Edition)

Vbot 9 Roboter

Roboter-Netzteil

Ethernet-Kabel

Großer eletrischer Drehteller

T-förmiger Target-Stab

Ankerblock × 16

Scanner-Kabel (Tracker – Scanner)

Kabelklemme

Scanner-Montagekit

Adapter

Inbusschrauben-Set

Schlitzschraubendreher

Einstellstift

Dockingstation
Specifications
| Metrohub 09 TR Robot 3D Scanning System | |
|---|---|
| Main components | Trackit SR Optical Tracking 3D Scanner, Robot Vbot 9 |
| Metrohub 09TR Volumetric Accuracy① | 0.025 mm + 0.04 mm × L (m) |
| Scannable Object Dimensions | ∅500 mm × H 500 mm |
| Worktable Mounting Dimensions (L × W × H) | 90 × 90 × 80 cm |
| Robot Arm Operating Radius | 919 mm |
| Shipping Dimensions | Vbot 9: 91 × 55 × 52 cm Trackit SR: 98 × 27 × 42 cm |
| Total Weight | Vbot 9: 36.5 kg Trackit SR: 18.6 kg |
| Trackit SR Optical Tracking 3D Scanner | |||
|---|---|---|---|
| Main components | Trackit SR Optical Tracking 3D Scanner, Robot Vbot 9 | ||
| Metrohub 09TR Volumetric Accuracy① | 0.025 mm + 0.04 mm × L (m) | ||
| Scannable Object Dimensions | ∅500 mm × H 500 mm | ||
| Worktable Mounting Dimensions (L × W × H) | 90 × 90 × 80 cm | ||
| Robot Arm Operating Radius | 919 mm | ||
| Shipping Dimensions | Vbot 9: 91 × 55 × 52 cm Trackit SR: 98 × 27 × 42 cm |
||
| Total Weight | Vbot 9: 36.5 kg Trackit SR: 18.6 kg |
||
|
Scanner

|
Tracker

|
||
| Fused Point Distance, up to | 0.05 mm | Part Size Range (Recommended) | 0.01 - 4 m |
| Scanning Speed, up to | 2,000,000 Point/s | Working Distance | 800 mm - 2500 mm |
| Light Source② | Fine Mode: 30 Blue Cross Laser Lines Far Mode: 17 Blue Parallel Laser Lines Deep Hole Mode: 1 Blue Single Laser Line |
Minimum Tracking Frame | 587 × 569 mm @ 800 mm |
| Working Distance | Cross Laser Lines: 200 - 400 mm Parallel Laser Lines: 250 - 500 mm Single Laser Line: 200 - 400 mm |
Maximum Tracking Frame | 2075 × 1778 mm @ 2500 mm |
| Single Capture Area at Nearest Distance | 123 × 130 mm at 200 mm | Tracking Volume | 3 m³ |
| Single Capture Area at Furthest Distance | 330 × 325 mm at 500 mm | Weight | 1.5 kg |
| Weight | 1.0 kg | Dimensions (L × W × H) | 441 × 111 × 103 mm |
| Dimensions (L × W × H) | 250 × 250 × 177 mm | Tracking Band | NIR |
| Operating Temperature Range③ | 0 - 30 ℃ | ||
| Output Formats | PLY, OBJ, STL, ASC, 3MF, GLTF, FBX | ||
| Material | Frame: Carbon Fiber Housing: Polycarbonate |
||
| Robot | ||
|---|---|---|
|
Vbot 9

|
||
| Load | 5 kg | |
| Working Radius | 919 mm | |
| Weight | 17.5 kg | |
| Number of Axes | 6 | |
| Maximum TCP Speed | ≤2.0 m/s | |
| Operating Temperature | 0°C ~ +50°C | |
| Storage Temperature | -10°C ~ +55°C | |
| Maximum Humidity | 0%~93%, non-condensing, non-frosting | |
| Joint Range of Motion (ROM) | Axis J1 | ±360° |
| Axis J2 | ±135° | |
| Axis J3 | -170°~ +140° | |
| Axis J4 | ±360° | |
| Axis J5 | ±360° | |
| Axis J6 | ±360° | |
| Single-Joint Speed | Axis J1 | 180°/s |
| Axis J2 | 180°/s | |
| Axis J3 | 180°/s | |
| Axis J4 | 180°/s | |
| Axis J5 | 180°/s | |
| Axis J6 | 180°/s | |
| Noise level | ≤70dB(A) | |
| Control Type | Built-in | |
|
Note ① Volumetric Accuracy are acquired in a controlled lab environment. Actual results might vary, subject to the operation environment. ② Class 2 Laser Safety Tips: 1) The product uses a Class 2 laser projector. Avoid looking directly at it at close range! Please refer to the Class 2 laser standard document for details. 2) To avoid retina damage, don't look directly into the laser beam through optical instruments capable of magnifying it (e.g., telescopes, and camera lenses). 3) To prevent laser reflection, avoid placing reflective surfaces like mirrors or glass in the path of the laser beam. ③ To ensure accuracy, it's recommended to use the product within an environment temperature range of 20℃ to 25℃ (68℉ to 77℉). ④ This product has flashing lights, which may not be suitable for people with photosensitive epilepsy. |
||
FAQ
Does it support secondary development interfaces?
Are other brands of industrial and collaborative robots supported?
What's in the package?
Do I need to program and teach the robot?
What is the core difference between the Metrohub 09YU and 09TR?
How do Metrohub 09YU and Metrohub 09TR differ in accuracy and scanning efficiency?
(2) Speed: Metrohub 09YU reaches 3,000,000 points/s in multi-line laser mode and 7,000,000 points/s in full-field blue structured-light mode. Metrohub 09TR reaches 2,000,000 points/s for coordinated robot and optical-tracking acquisition.
How do the deployment requirements differ between Metrohub 09YU and Metrohub 09TR?
Which software is used with Metrohub 09YU and Metrohub 09TR? Are their functions the same?
What are the scanning-mode differences?
Metrohub 09TR supports stationary and turntable tracking. Stationary tracking suits smaller workpieces; turntable tracking coordinates the Tracker, Scanner, robot, and turntable for larger-workpiece capture.
How do the scanning workflows differ?
Metrohub 09TR manages the Tracker's field of view, hand-eye calibration, robot teaching paths, and turntable coordination. In stationary tracking mode, the Tracker and workpiece must remain still during scanning.