


- Photos


Nouveau
Automatisé
Flexible
Metrohub 09TR: Robotic Optical Tracking 3D Scanning System for Automated Scanning & Inspection
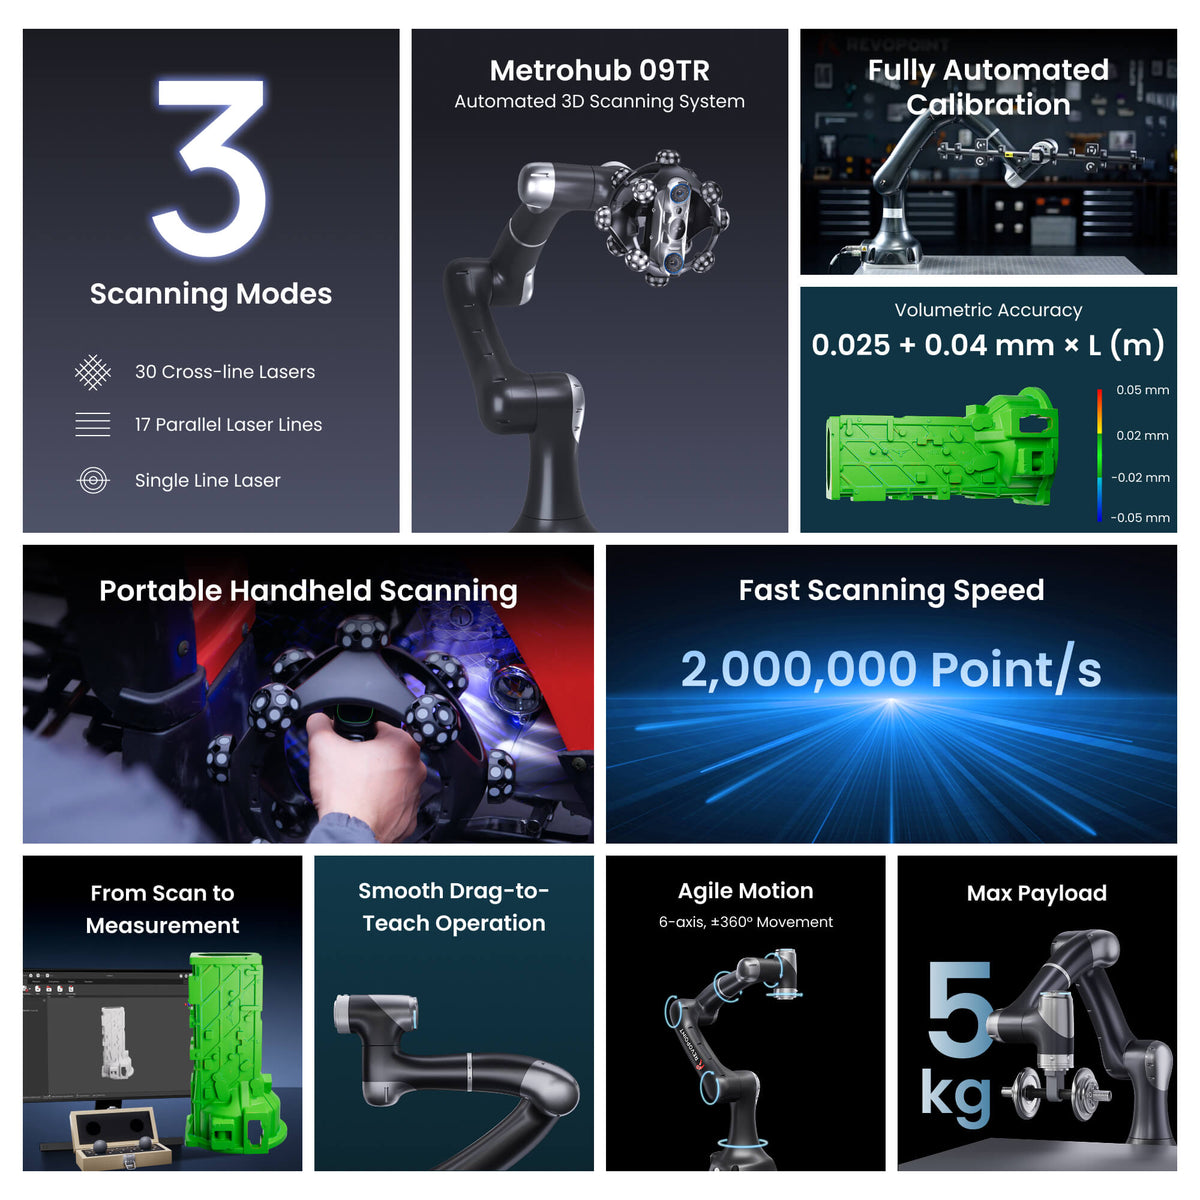
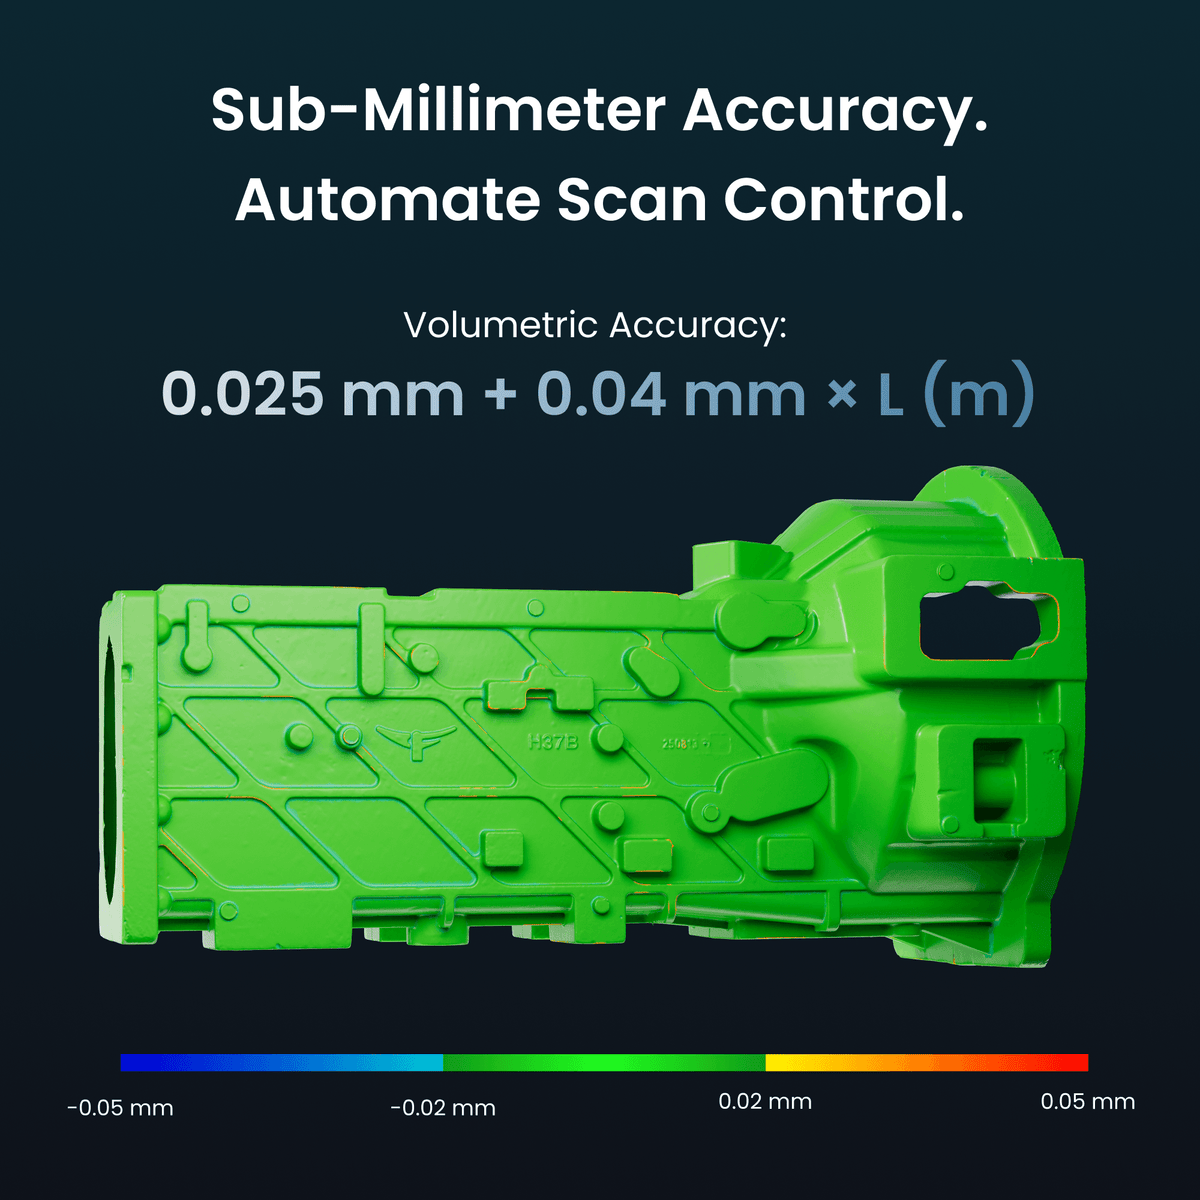
· Exactitude volumétrique : 0,025 mm + 0,04 mm × L (m)
· Capture par triple laser bleu
· Vitesse de numérisation rapide : 2 000 000 points/s
· Mesure et inspection 3D certifiées
· Mouvement agile : 6 axes, mouvement ±360°
· Automatisation 3D plug‑and‑play


Les unités précommandées seront expédiées à partir du 22 juin. Les logiciels ne sont pas remboursables et sont livrés rapidement par voie numérique par e-mail.


Features
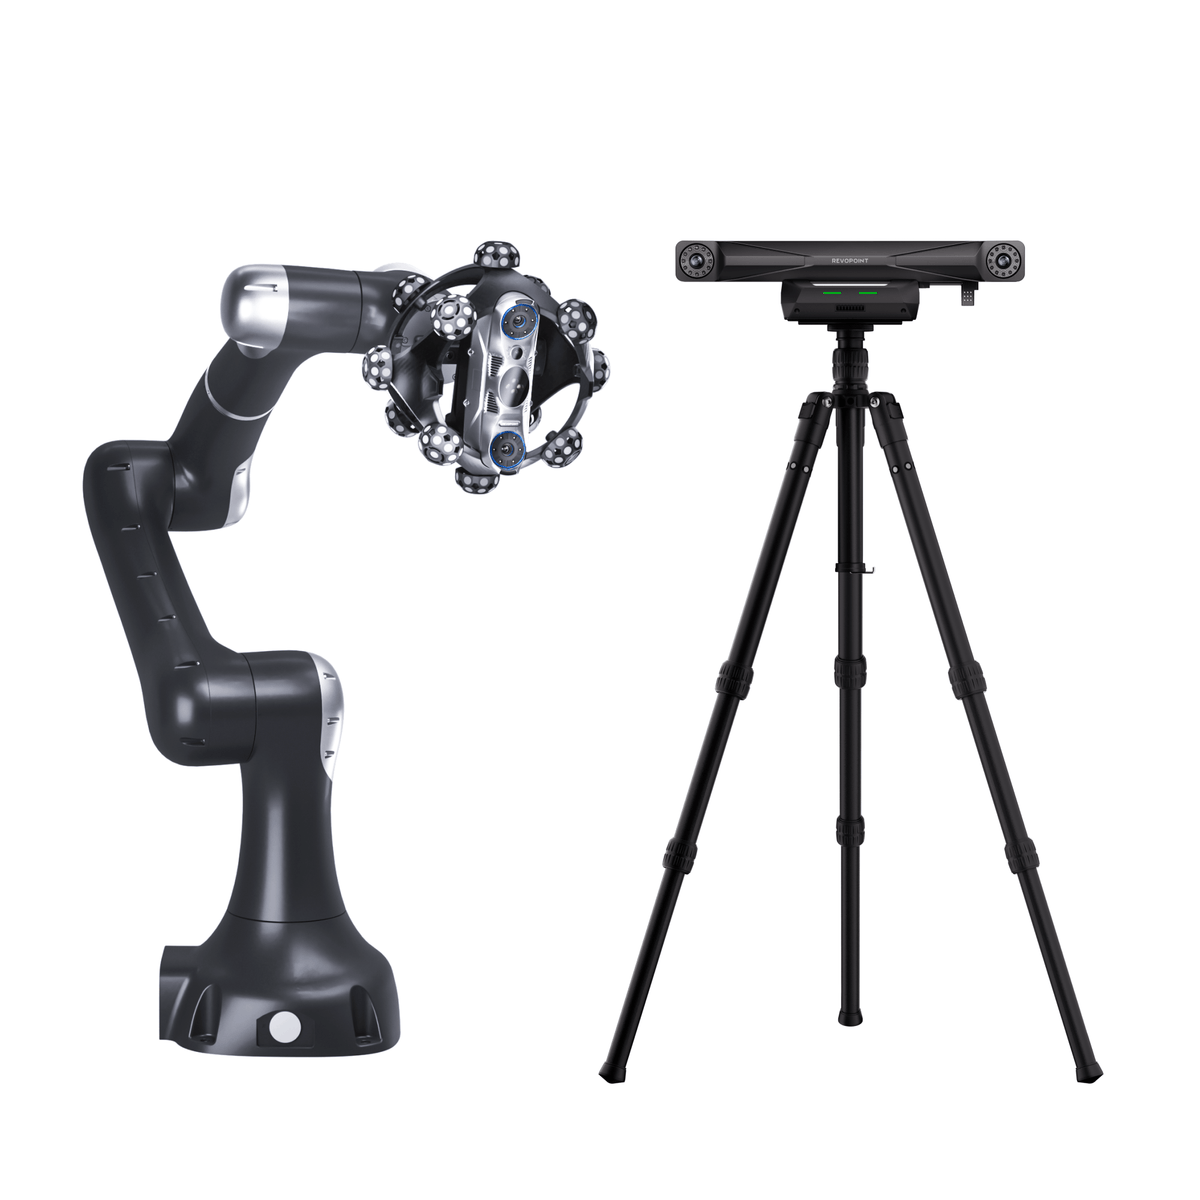
Le Metrohub 09TR intègre un scanner 3D de suivi optique haute précision *Trackit SR et le cobot 6 axes Vbot 9, une table tournante CNC et le logiciel TrackBot pour un scan multi-angle automatisé, une analyse de mesure et des rapports d'inspection — avec planification de trajectoire par apprentissage manuel (drag-to-teach), détection de force et une conception de sécurité collaborative.


Précision inférieure au millimètre. Contrôle de scan automatisé.
Propulsé par le Vbot 9 à 6 axes, le scan multi-angle automatisé couvre les pièces courbes, de forme libre et à cavités profondes.
Précision volumétrique :
0,025 mm + 0,04 mm × L (m)
Distance entre points fusionnés
Jusqu'à 0,05 mm


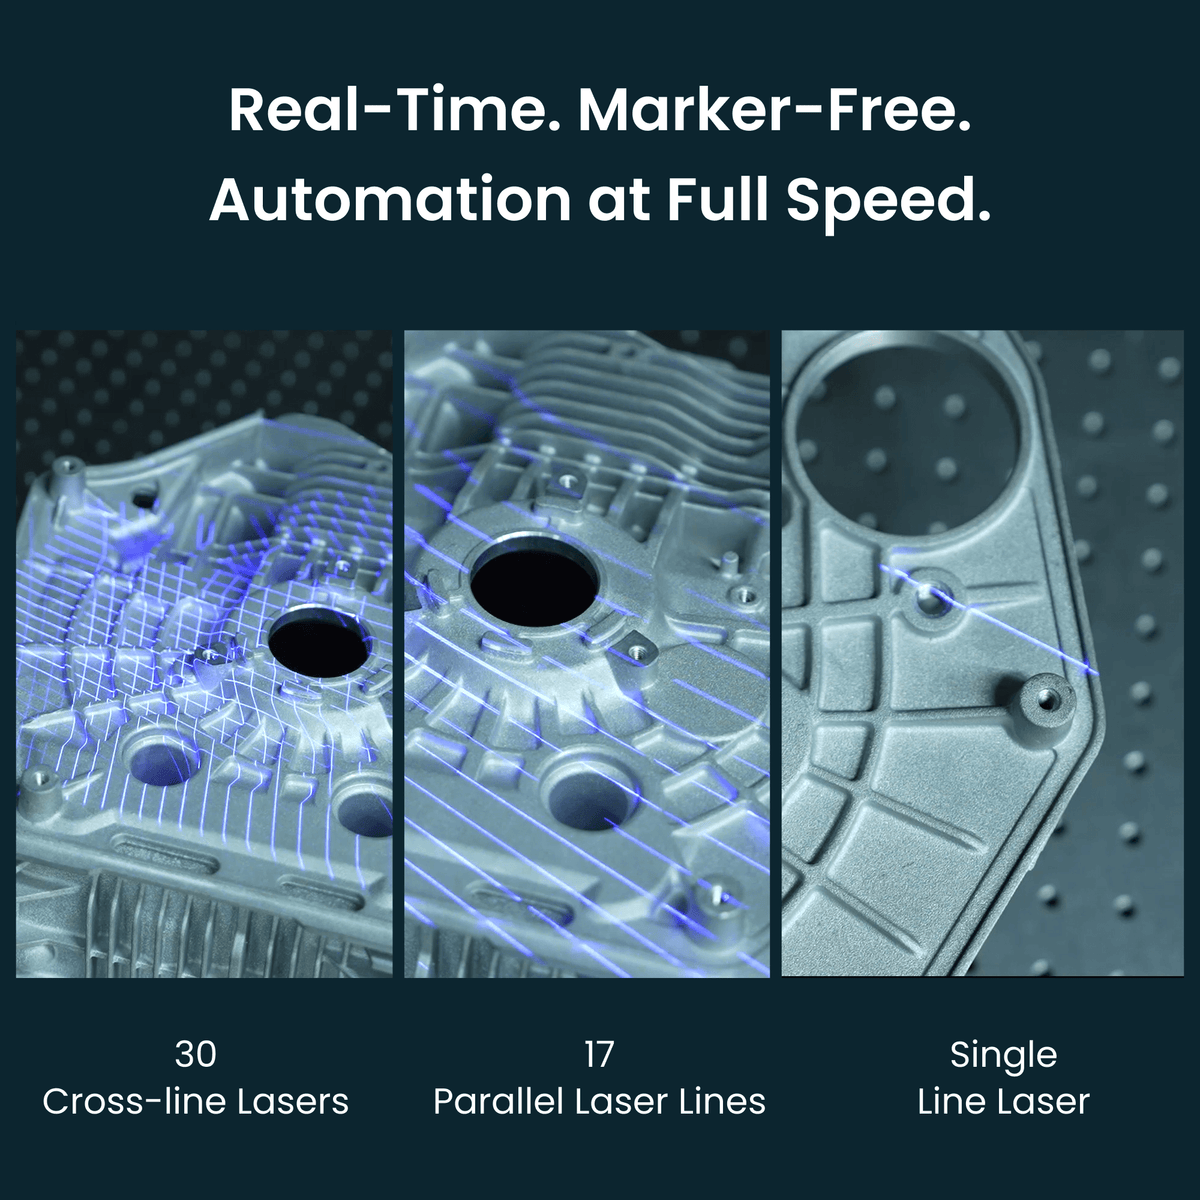
Temps réel. Sans marqueur. Automatisation à pleine vitesse.
Les lasers du Trackit SR – 30 lignes croisées, 17 lignes parallèles et une ligne simple – permettent un scan sans marqueur des surfaces noires, réfléchissantes et métalliques à une vitesse allant jusqu'à 2 000 000 points/s.


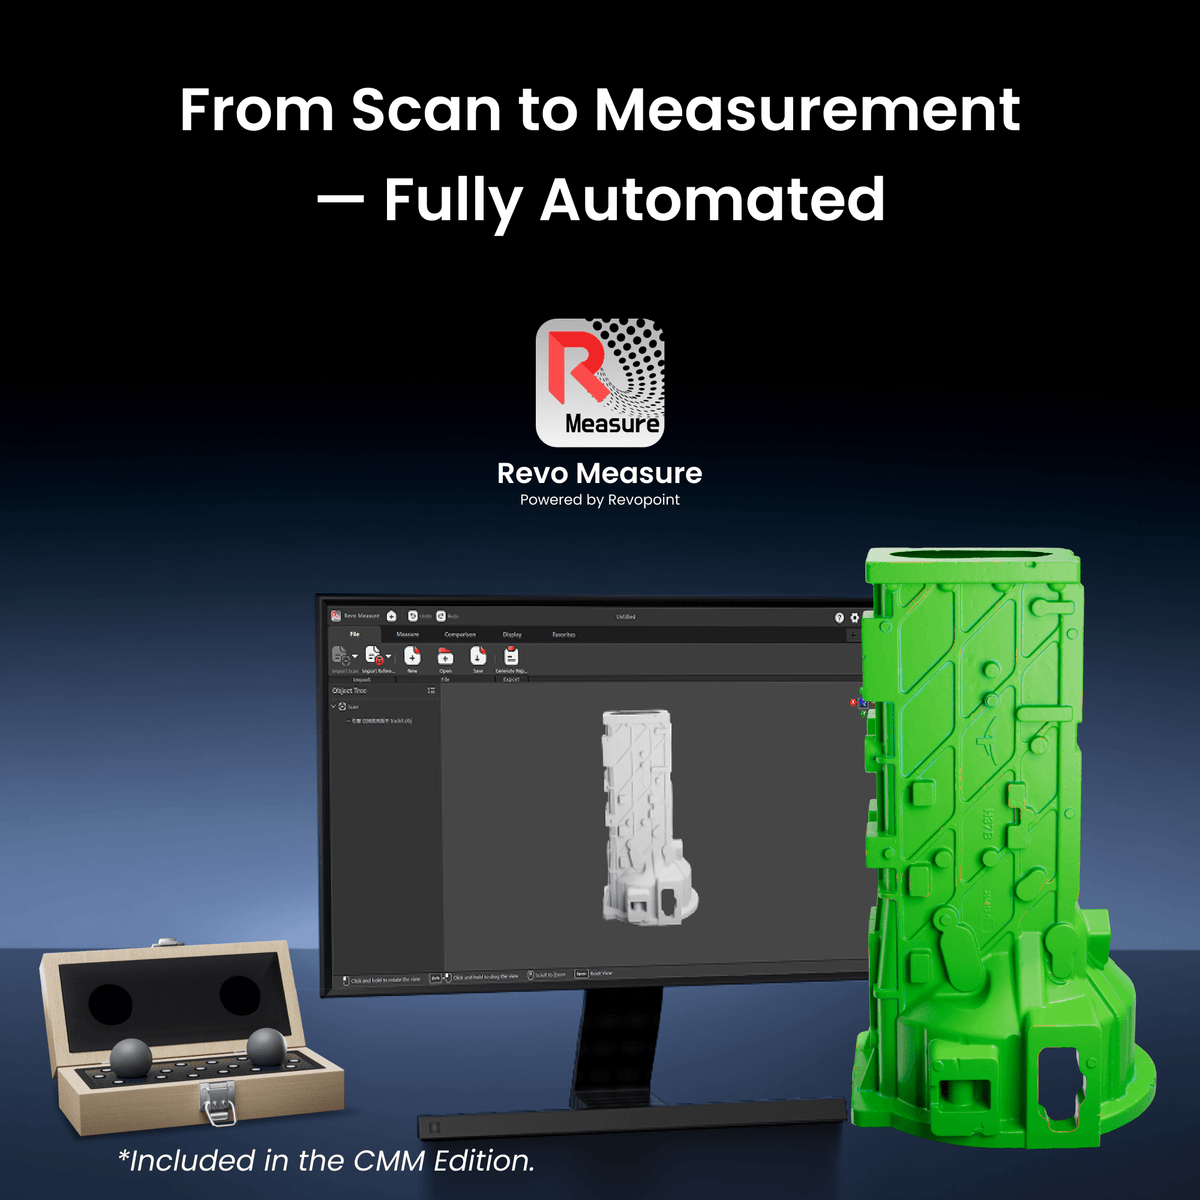
Du scan à la mesure — entièrement automatisé
Le Metrohub 09TR prend en charge des modèles prédéfinis pour les flux d'inspection par lots — déclenchant automatiquement *Revo Measure pour l'inspection dimensionnelle, l'analyse GD&T et la sortie des résultats.
*Inclus dans l'édition CMM.


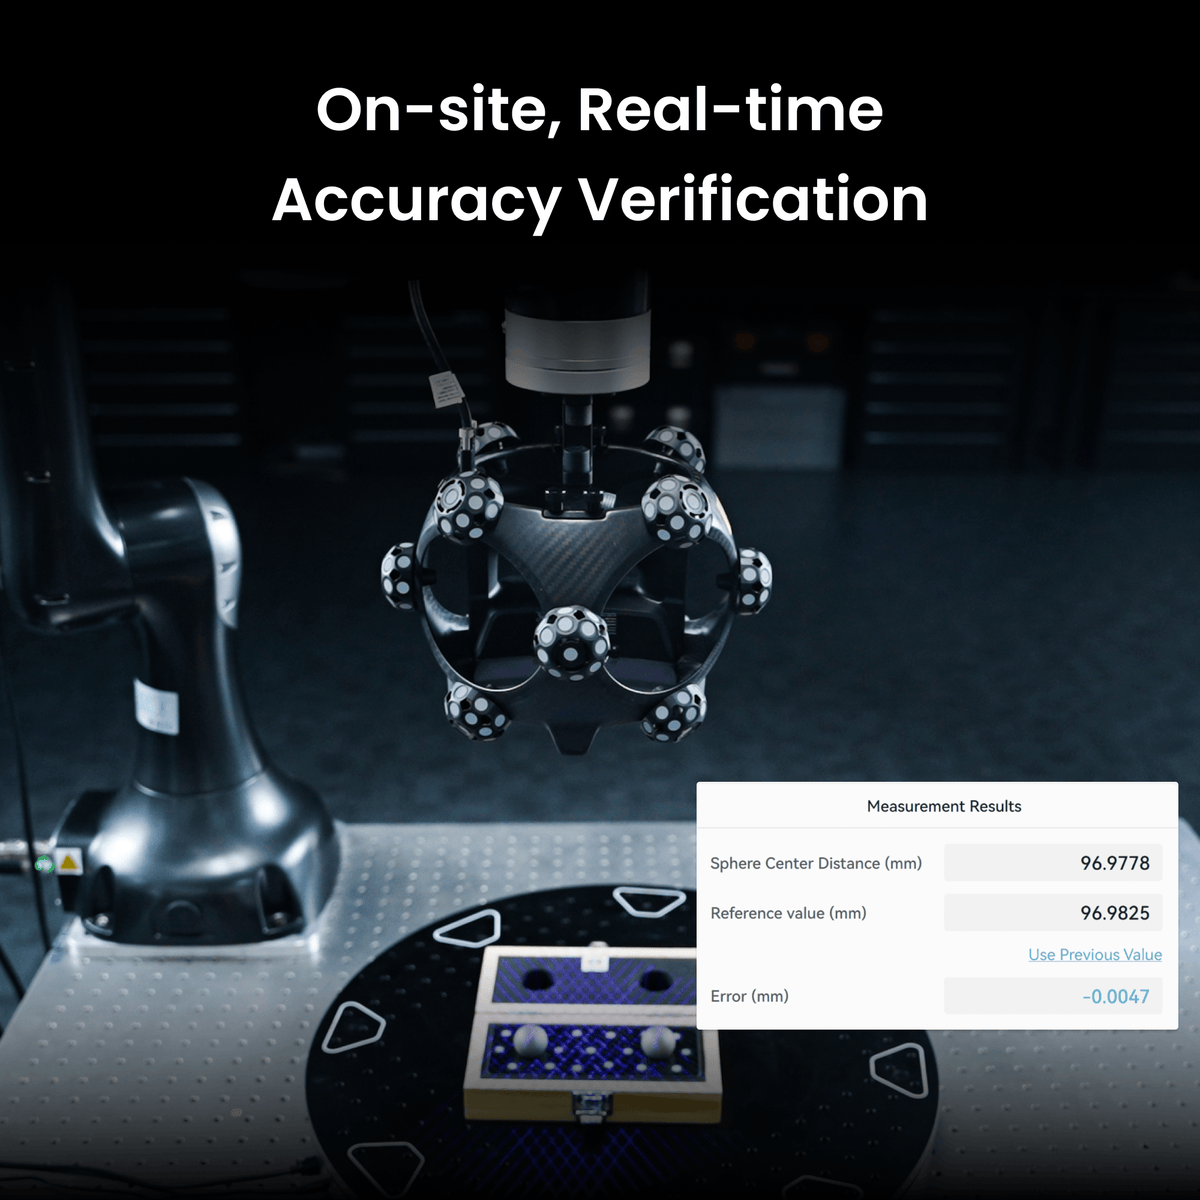
On-site, Real-time
Accuracy Verification
Metrohub 09TR's metrology-grade *Ball Plate and automated verification workflow deliver instant on-site accuracy confirmation in TrackBot.
*Included in the CMM Edition.

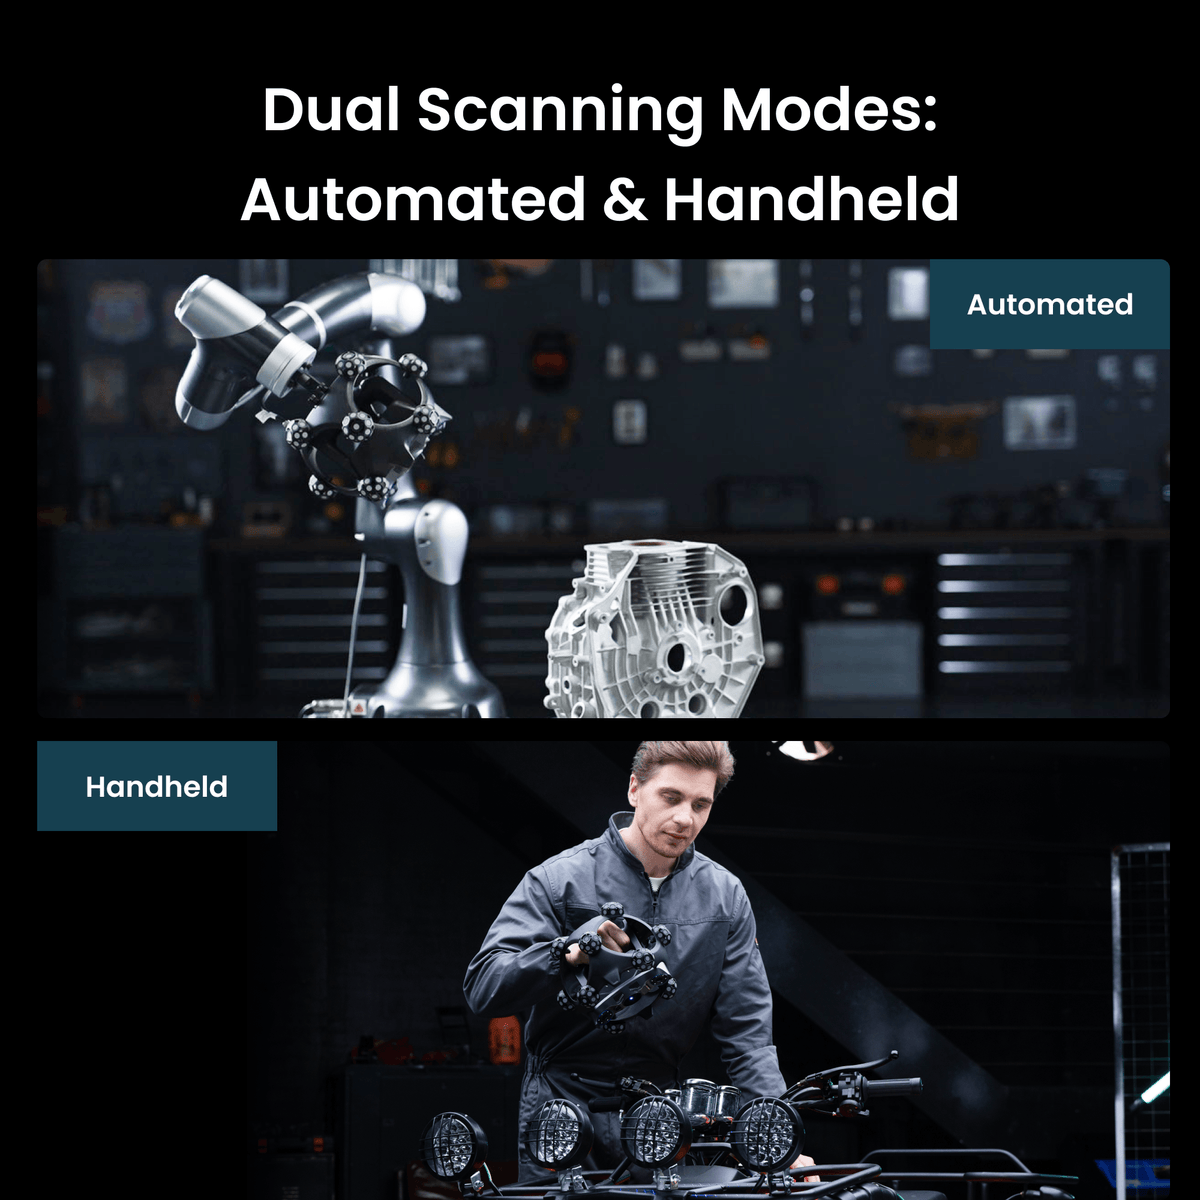
Dual Scanning Modes: Automated & Handheld
It also operates wirelessly and independently for standalone marker scanning.


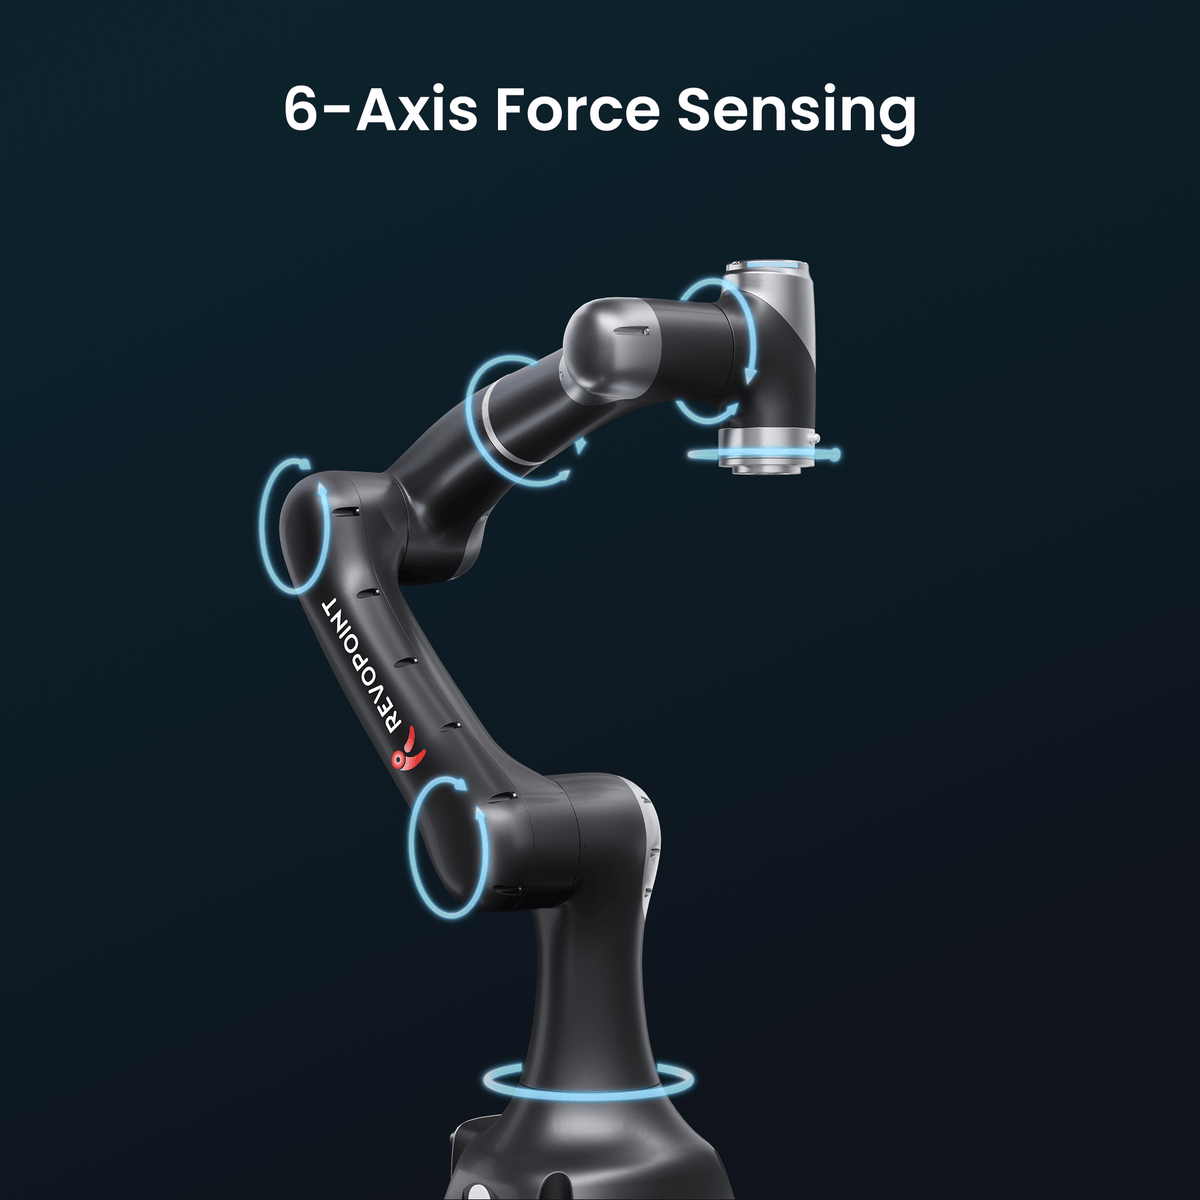
Détection de force 6 axes — ressentez chaque mouvement
Les capteurs de force 6 axes intégrés du Vbot 9 offrent un retour de force ultra-sensible et un contrôle de force en temps réel.


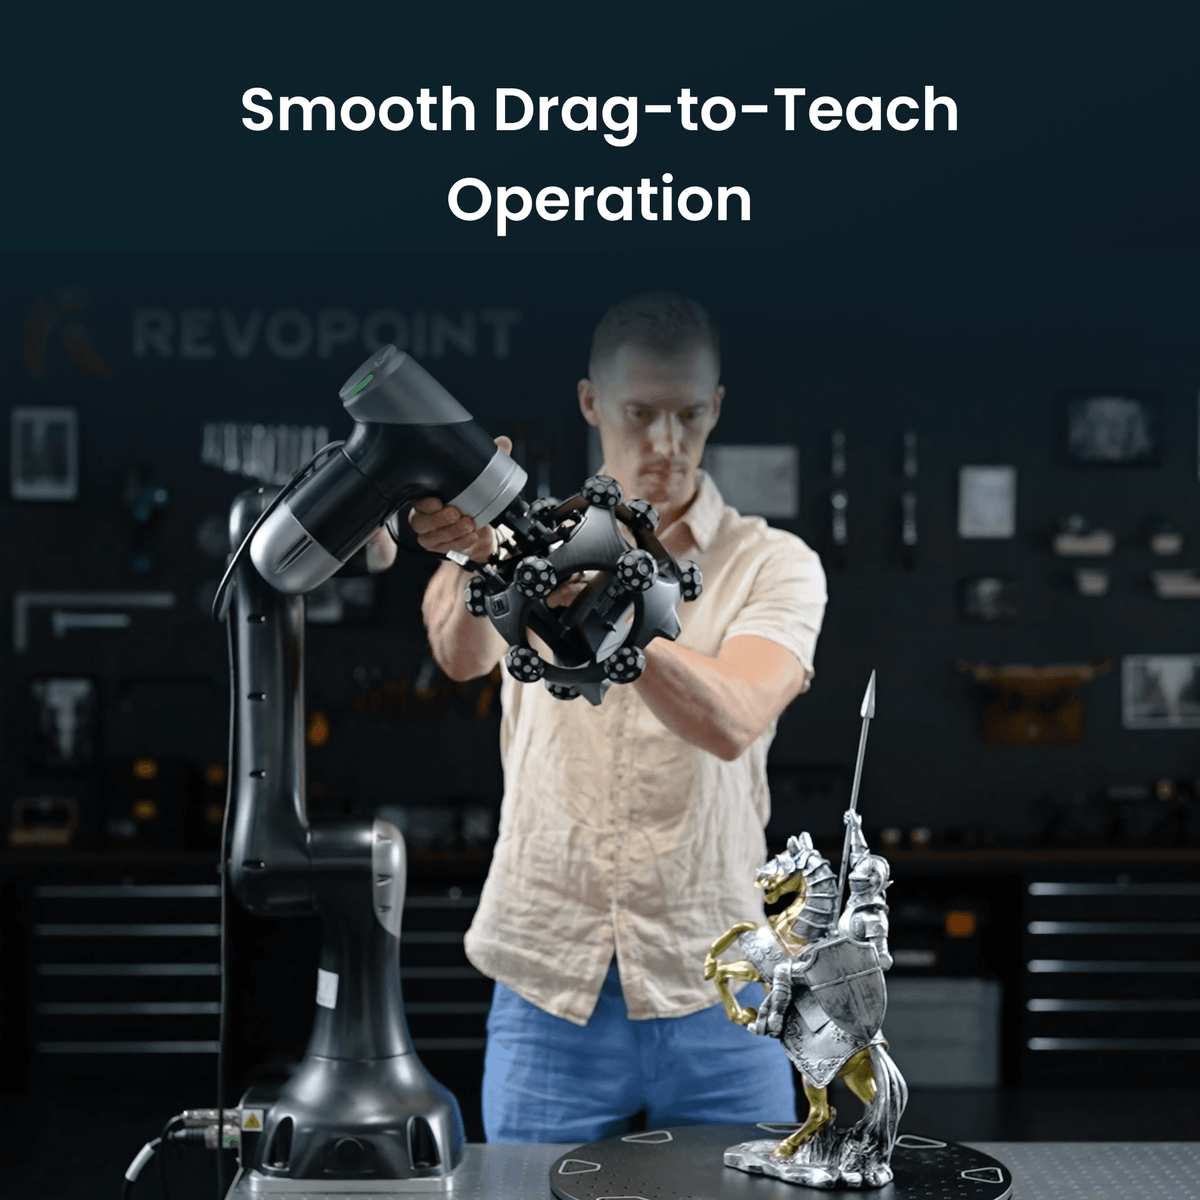
Fonctionnement fluide par apprentissage manuel (drag-to-teach)
Pré-scan pour vérifier les trajectoires du robot, la couverture du scan et la qualité des données — maximisant le succès du scan.


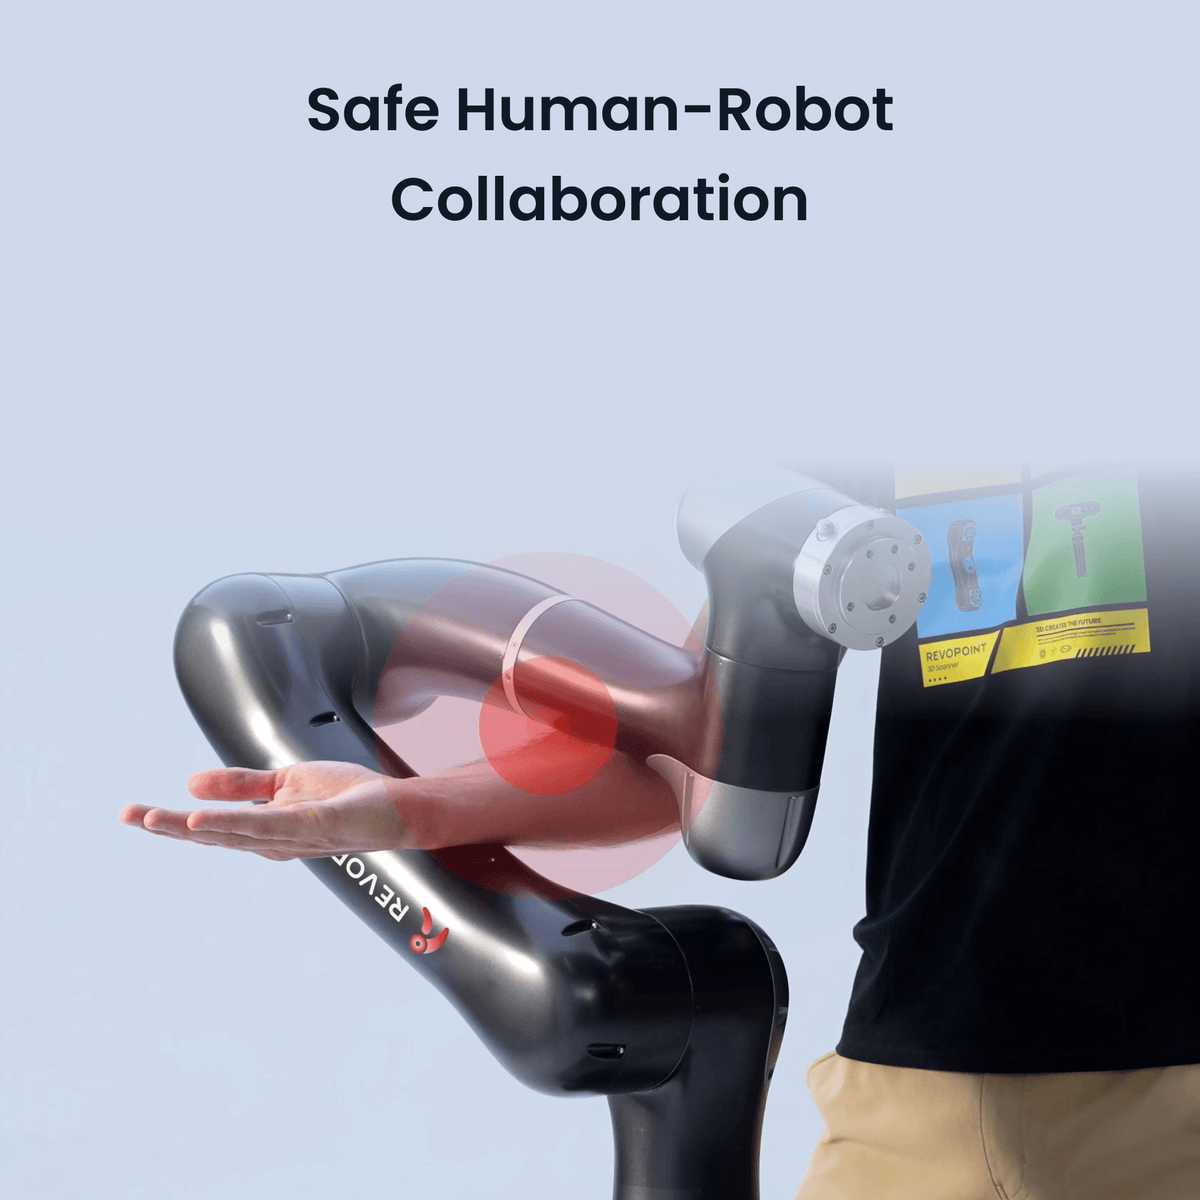
Security Collaboration
Work safely alongside the robot — no safety fences required. 1N force sensitivity ensures complete collision protection.


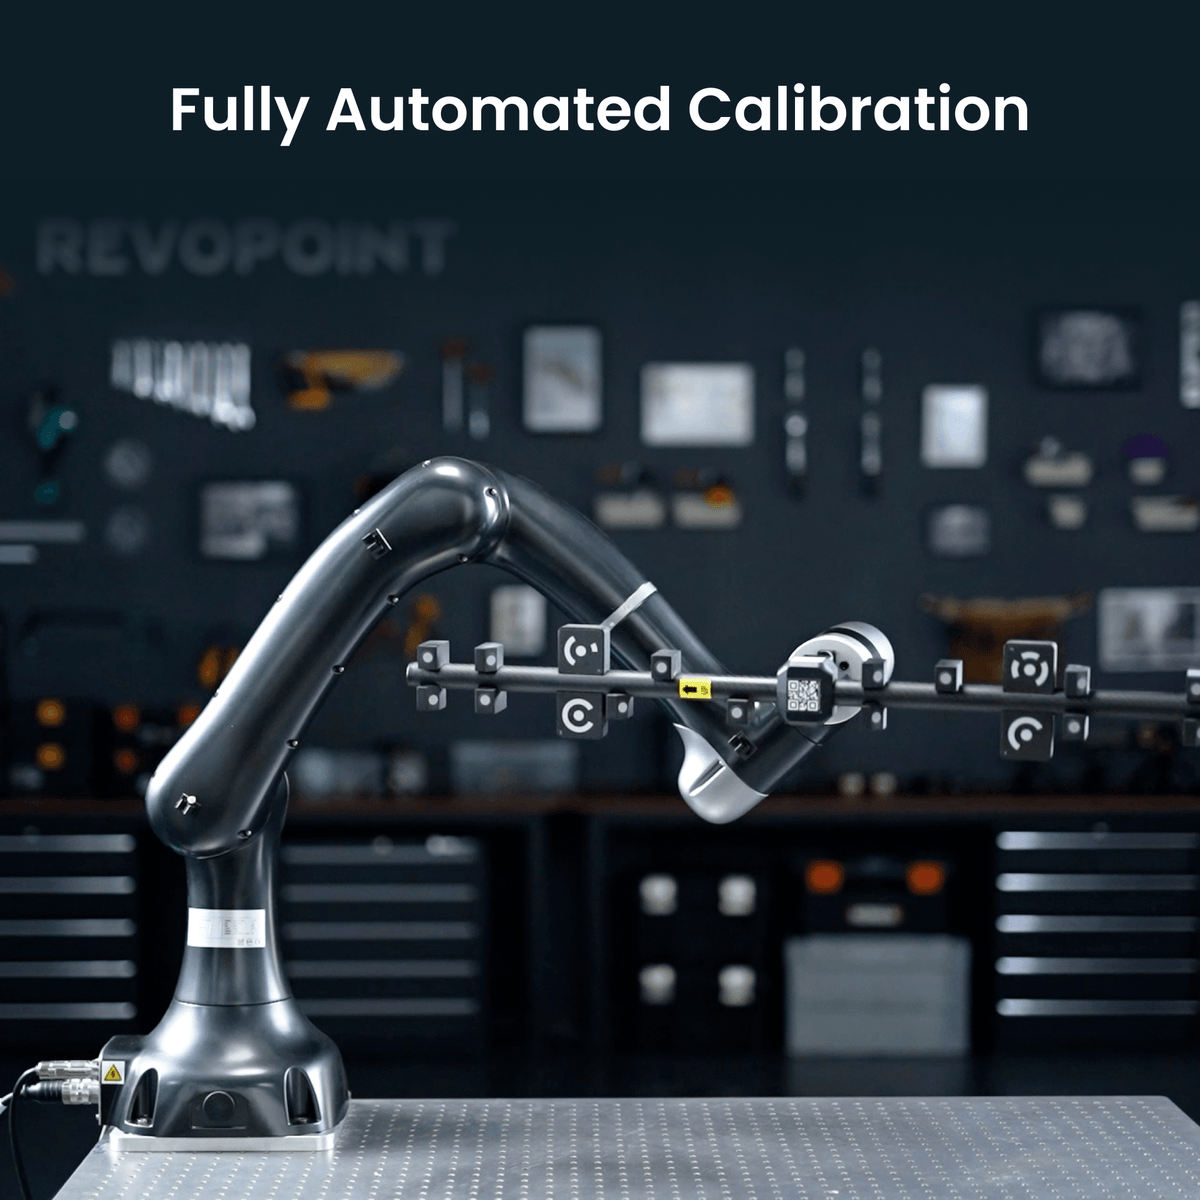
Calibration automatisée rapide
Obtenez une calibration multi-pose parfaite, exempte d'erreur humaine, grâce au système d'auto-calibration de Trackit SR et Vbot 9 — fiable, précis et simple.


Kit de développement tiers
Un protocole de contrôle TCP/IP connecte les applications tierces à Revo Track pour un contrôle en temps réel du scan et du post-traitement
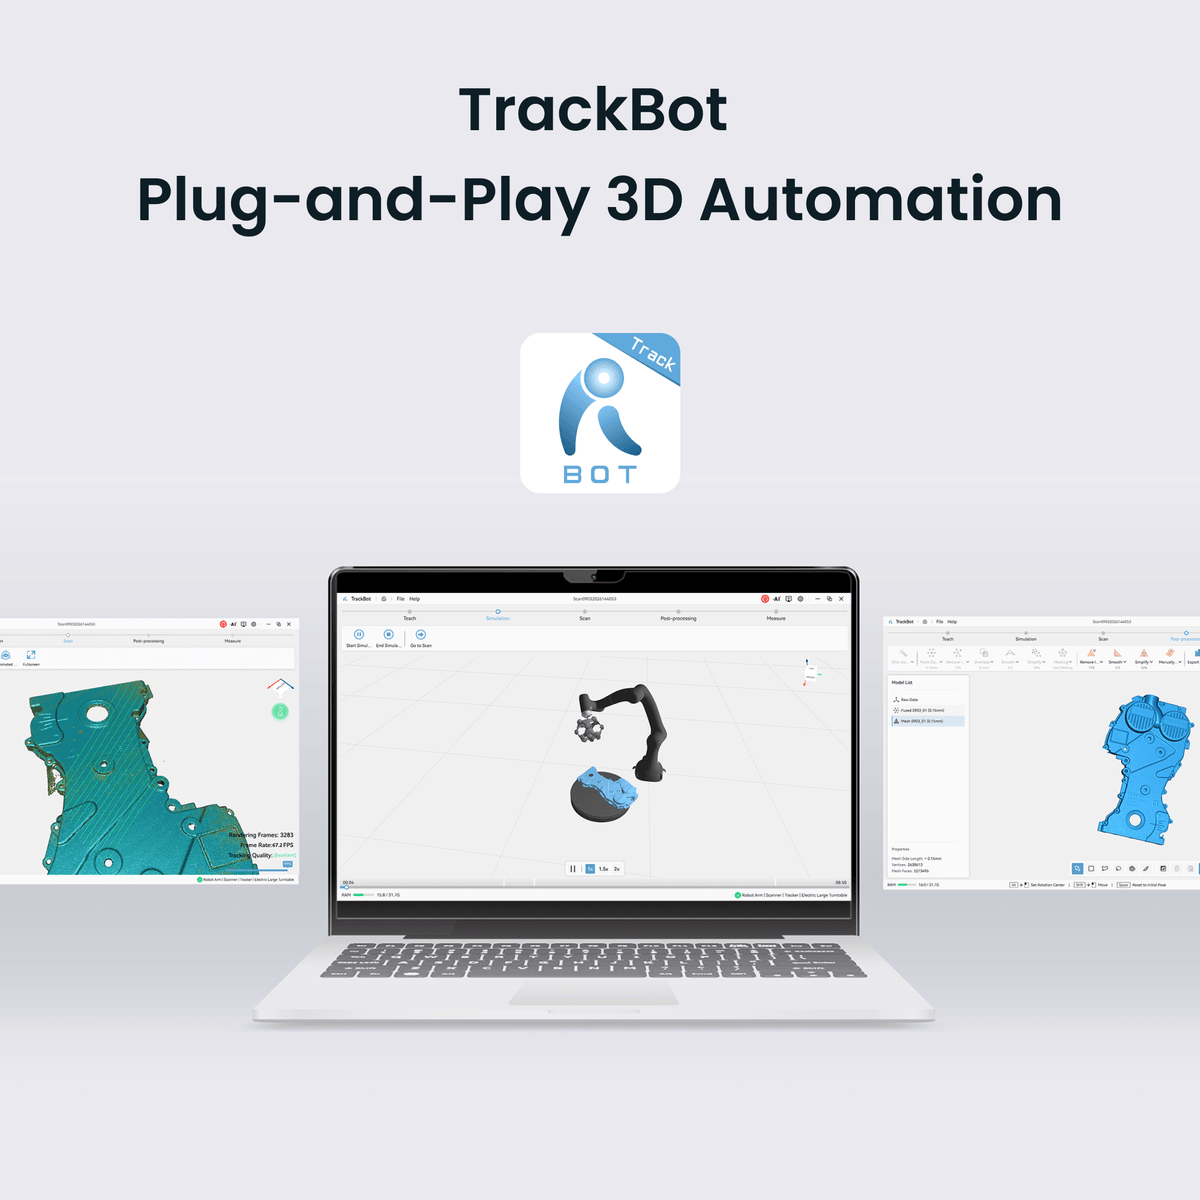
TrackBot — Plug-and-Play 3D Automation
Set up automated scans in minutes — drag-to-teach, CAD-to-path, or vision-to-path. No programming required.


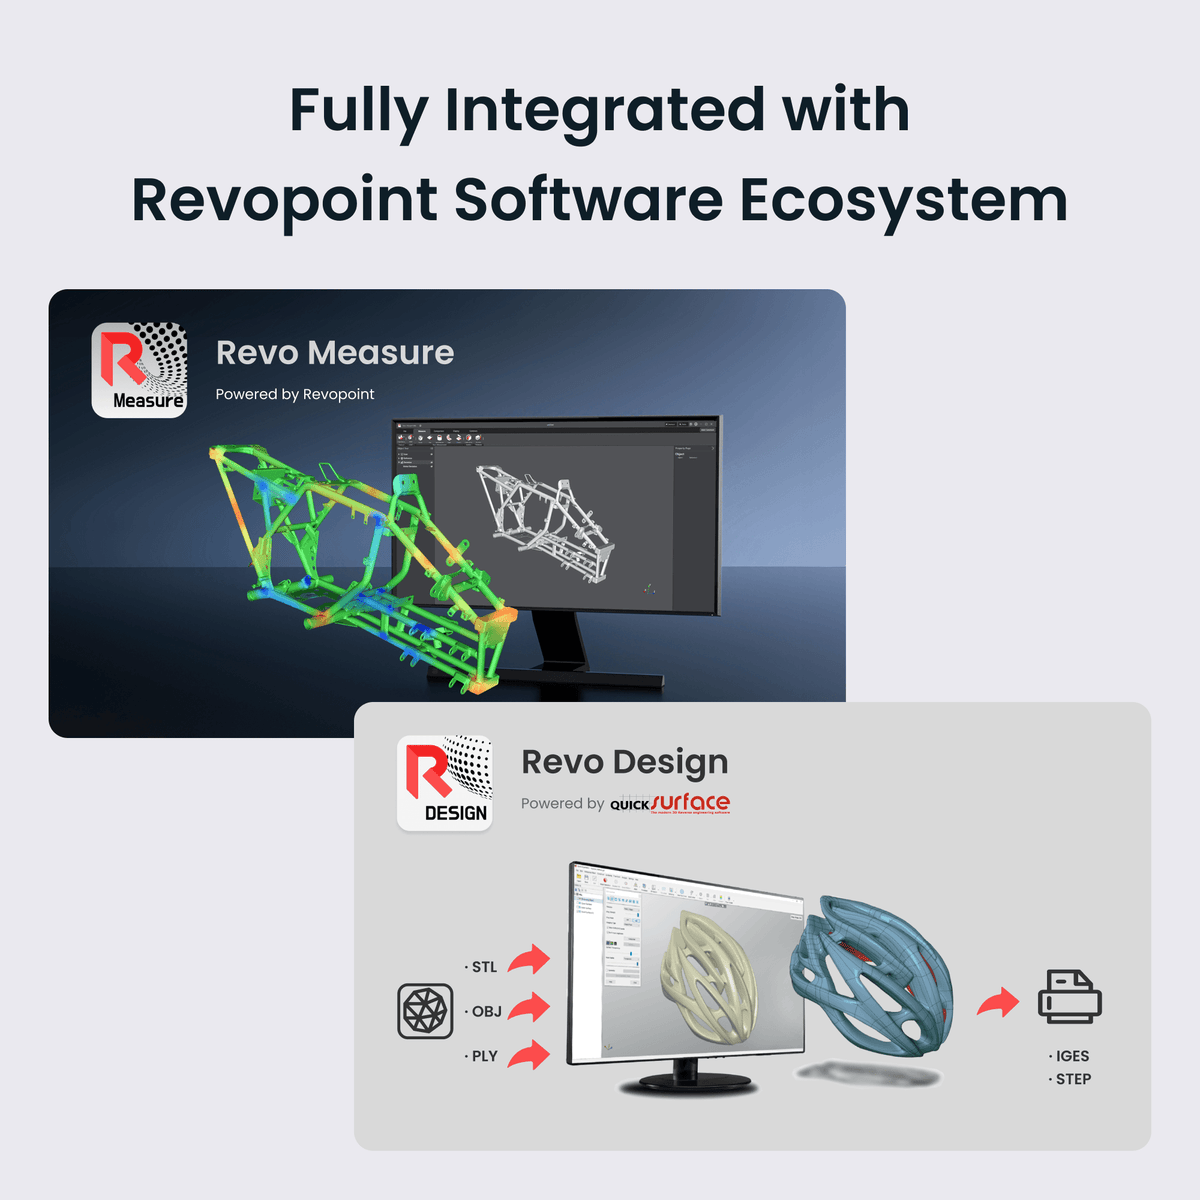
Fully Integrated with
Revopoint Software Ecosystem
Integrate with Revo Measure for one-click measurements,
CAD comparison, and 10+ GD&T functions.


Détachable et flexible
Le scanner Trackit SR se détache du Vbot 9 pour une utilisation manuelle indépendante – vous offrant la flexibilité de passer d’une numérisation robotisée entièrement automatisée à une numérisation manuelle sans modifier votre configuration.

Trackit SR Tracking 3D Scanner
Detach the scanner for wireless, standalone markerless scanning — ideal for complex structures, or any scenario where the robotic arm cannot reach. Maintains high-precision scanning accuracy in both robotic and handheld modes.
Learn More
Robot Vbot 9
Lightweight, 6-axis cobot with a 919 mm working radius and 1N force sensitivity for safe human-robot collaboration. Pairs seamlessly with the Trackit SR for automated multi-pose scanning across complex workpieces.
ExploreProfessional Solutions

Numérisation 3D automatisée
Planifiez automatiquement les trajectoires de numérisation multi‑postures sur les surfaces de pales et les caractéristiques de pied, avec évitement de collision par IA – capture complète du nuage de points à 360° en une seule configuration.

Fabrication additive
Capturez automatiquement les nuages de points des surplombs, structures en treillis et cavités internes – générez des données STL pour la réparation de modèles, la compensation de procédé et la refabrication.

Fonderie et forge
Numérisez automatiquement les pièces coulées et les pièces à chaud avec compensation thermique en temps réel – identifiez rapidement les écarts de matière, les retraits et les défauts de surface pour accélérer la correction des moules.

Plastiques
Inspection automatisée des pièces moulées par injection, extrudées‑soufflées et thermoformées – détection des retraits, déformations, retours élastiques et déformations de contour sur l’ensemble de la production.

Formage des métaux
Numérisez automatiquement les cordons de soudure, positions de trous et profils de surface sur les panneaux de carrosserie automobile – comparez les nuages de points au modèle CAO avec des interfaces TCP/IP ouvertes pour l’intégration en ligne de production.

Inspection des batteries
La numérisation robotisée multi‑postures couvre les six faces, les zones d’étanchéité et les bornes des boîtiers de batteries prismatiques – détection des gonflements, bosses, désalignements d’étanchéité et écarts dimensionnels.
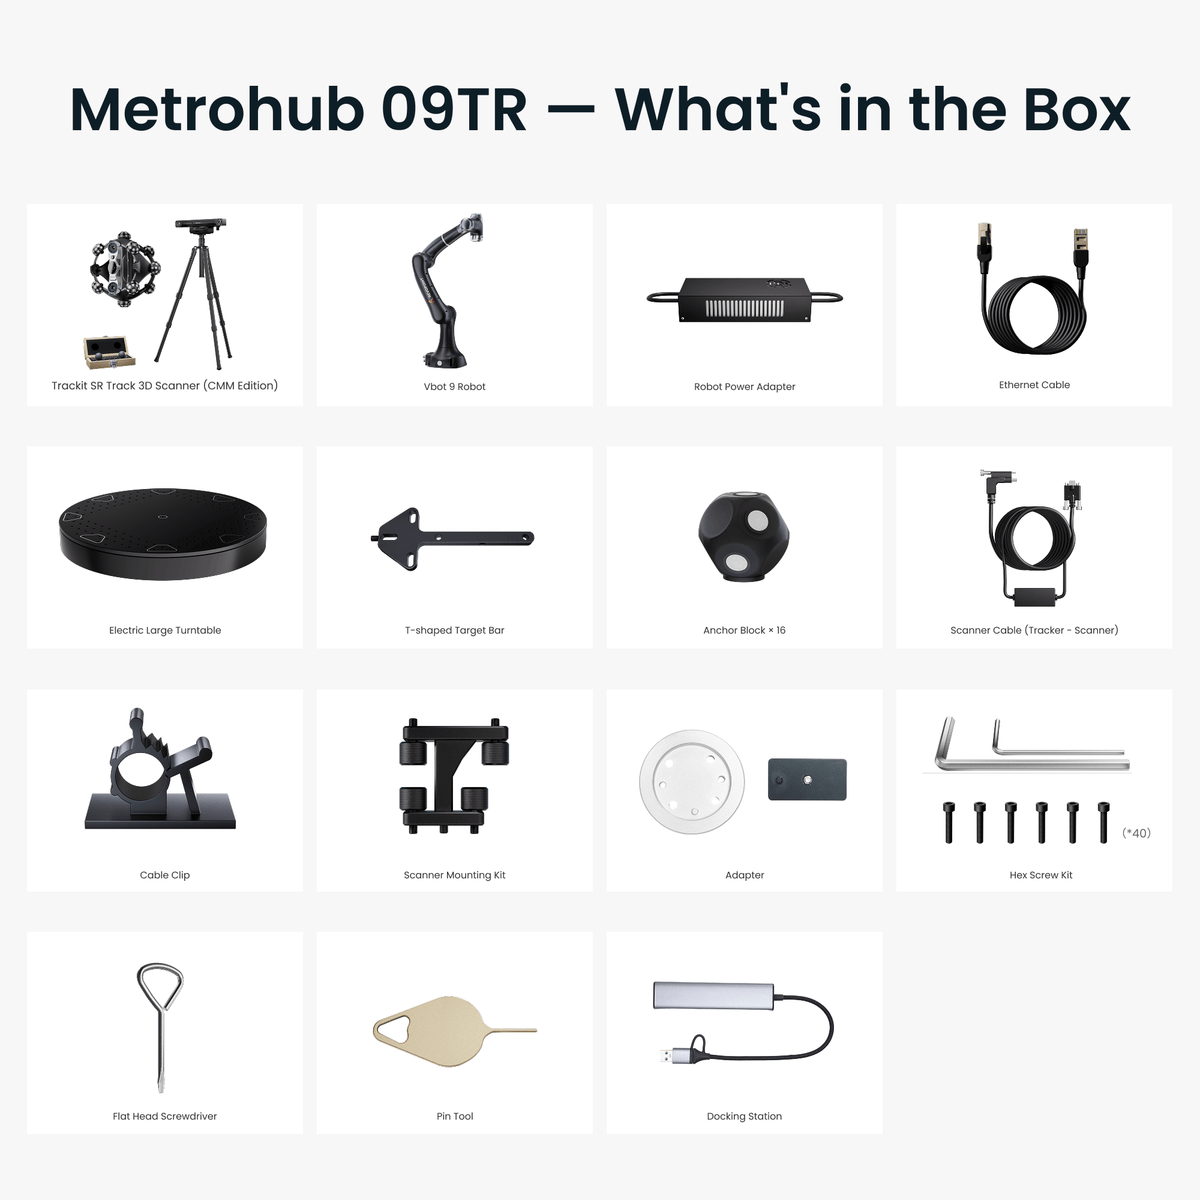
What’s in the Box?

Trackit SR – Scanner 3D à suivi (Édition CMM)

Robot Vbot 9

Adaptateur secteur du robot

Câble Ethernet

Grand plateau tournant électrique

Barre cible en T

Bloc d'ancrage × 16

Câble Scanner (Tracker – Scanner)

Clips de câble

Kit de montage du scanner

Adaptateur

Kit de vis hexagonales

Tournevis plat

Outil de dégagement

Station d'accueil
Specifications
| Metrohub 09 TR Robot 3D Scanning System | |
|---|---|
| Main components | Trackit SR Optical Tracking 3D Scanner, Robot Vbot 9 |
| Metrohub 09TR Volumetric Accuracy① | 0.025 mm + 0.04 mm × L (m) |
| Scannable Object Dimensions | ∅500 mm × H 500 mm |
| Worktable Mounting Dimensions (L × W × H) | 90 × 90 × 80 cm |
| Robot Arm Operating Radius | 919 mm |
| Shipping Dimensions | Vbot 9: 91 × 55 × 52 cm Trackit SR: 98 × 27 × 42 cm |
| Total Weight | Vbot 9: 36.5 kg Trackit SR: 18.6 kg |
| Trackit SR Optical Tracking 3D Scanner | |||
|---|---|---|---|
| Main components | Trackit SR Optical Tracking 3D Scanner, Robot Vbot 9 | ||
| Metrohub 09TR Volumetric Accuracy① | 0.025 mm + 0.04 mm × L (m) | ||
| Scannable Object Dimensions | ∅500 mm × H 500 mm | ||
| Worktable Mounting Dimensions (L × W × H) | 90 × 90 × 80 cm | ||
| Robot Arm Operating Radius | 919 mm | ||
| Shipping Dimensions | Vbot 9: 91 × 55 × 52 cm Trackit SR: 98 × 27 × 42 cm |
||
| Total Weight | Vbot 9: 36.5 kg Trackit SR: 18.6 kg |
||
|
Scanner

|
Tracker

|
||
| Fused Point Distance, up to | 0.05 mm | Part Size Range (Recommended) | 0.01 - 4 m |
| Scanning Speed, up to | 2,000,000 Point/s | Working Distance | 800 mm - 2500 mm |
| Light Source② | Fine Mode: 30 Blue Cross Laser Lines Far Mode: 17 Blue Parallel Laser Lines Deep Hole Mode: 1 Blue Single Laser Line |
Minimum Tracking Frame | 587 × 569 mm @ 800 mm |
| Working Distance | Cross Laser Lines: 200 - 400 mm Parallel Laser Lines: 250 - 500 mm Single Laser Line: 200 - 400 mm |
Maximum Tracking Frame | 2075 × 1778 mm @ 2500 mm |
| Single Capture Area at Nearest Distance | 123 × 130 mm at 200 mm | Tracking Volume | 3 m³ |
| Single Capture Area at Furthest Distance | 330 × 325 mm at 500 mm | Weight | 1.5 kg |
| Weight | 1.0 kg | Dimensions (L × W × H) | 441 × 111 × 103 mm |
| Dimensions (L × W × H) | 250 × 250 × 177 mm | Tracking Band | NIR |
| Operating Temperature Range③ | 0 - 30 ℃ | ||
| Output Formats | PLY, OBJ, STL, ASC, 3MF, GLTF, FBX | ||
| Material | Frame: Carbon Fiber Housing: Polycarbonate |
||
| Robot | ||
|---|---|---|
|
Vbot 9

|
||
| Load | 5 kg | |
| Working Radius | 919 mm | |
| Weight | 17.5 kg | |
| Number of Axes | 6 | |
| Maximum TCP Speed | ≤2.0 m/s | |
| Operating Temperature | 0°C ~ +50°C | |
| Storage Temperature | -10°C ~ +55°C | |
| Maximum Humidity | 0%~93%, non-condensing, non-frosting | |
| Joint Range of Motion (ROM) | Axis J1 | ±360° |
| Axis J2 | ±135° | |
| Axis J3 | -170°~ +140° | |
| Axis J4 | ±360° | |
| Axis J5 | ±360° | |
| Axis J6 | ±360° | |
| Single-Joint Speed | Axis J1 | 180°/s |
| Axis J2 | 180°/s | |
| Axis J3 | 180°/s | |
| Axis J4 | 180°/s | |
| Axis J5 | 180°/s | |
| Axis J6 | 180°/s | |
| Noise level | ≤70dB(A) | |
| Control Type | Built-in | |
|
Note ① Volumetric Accuracy are acquired in a controlled lab environment. Actual results might vary, subject to the operation environment. ② Class 2 Laser Safety Tips: 1) The product uses a Class 2 laser projector. Avoid looking directly at it at close range! Please refer to the Class 2 laser standard document for details. 2) To avoid retina damage, don't look directly into the laser beam through optical instruments capable of magnifying it (e.g., telescopes, and camera lenses). 3) To prevent laser reflection, avoid placing reflective surfaces like mirrors or glass in the path of the laser beam. ③ To ensure accuracy, it's recommended to use the product within an environment temperature range of 20℃ to 25℃ (68℉ to 77℉). ④ This product has flashing lights, which may not be suitable for people with photosensitive epilepsy. |
||
FAQ
Does it support secondary development interfaces?
Are other brands of industrial and collaborative robots supported?
What's in the package?
Do I need to program and teach the robot?
What is the core difference between the Metrohub 09YU and 09TR?
How do Metrohub 09YU and Metrohub 09TR differ in accuracy and scanning efficiency?
(2) Speed: Metrohub 09YU reaches 3,000,000 points/s in multi-line laser mode and 7,000,000 points/s in full-field blue structured-light mode. Metrohub 09TR reaches 2,000,000 points/s for coordinated robot and optical-tracking acquisition.
How do the deployment requirements differ between Metrohub 09YU and Metrohub 09TR?
Which software is used with Metrohub 09YU and Metrohub 09TR? Are their functions the same?
What are the scanning-mode differences?
Metrohub 09TR supports stationary and turntable tracking. Stationary tracking suits smaller workpieces; turntable tracking coordinates the Tracker, Scanner, robot, and turntable for larger-workpiece capture.
How do the scanning workflows differ?
Metrohub 09TR manages the Tracker's field of view, hand-eye calibration, robot teaching paths, and turntable coordination. In stationary tracking mode, the Tracker and workpiece must remain still during scanning.